EO/IR tracking & pan-tilt platforms
Payload inertia, direction changes and cable travel shape positioning performance.
Review the motor, transmission, output support and feedback interfaces around the required motion cycle.
Components & custom assemblies for OEMs
Magnets and magnetic assemblies. Specialty motors and actuators. Force and torque sensors. Choose component supply, a matched measurement kit or a custom assembly developed around your application.
From one component to a defined assembly.
Design, prototype and plan production around the selected scope.
From concept to production
Move forward through a clear application brief, an agreed design direction, prototype revisions and a production plan. Define the work and acceptance records for the selected assembly at each stage.
Align the load cycle, interfaces and acceptance targets.
Compare architectures and examine design assumptions.
Build the revision around the key design decisions.
Measure the agreed configuration and refine the next revision.
Plan pilot builds, production resources and repeat supply.
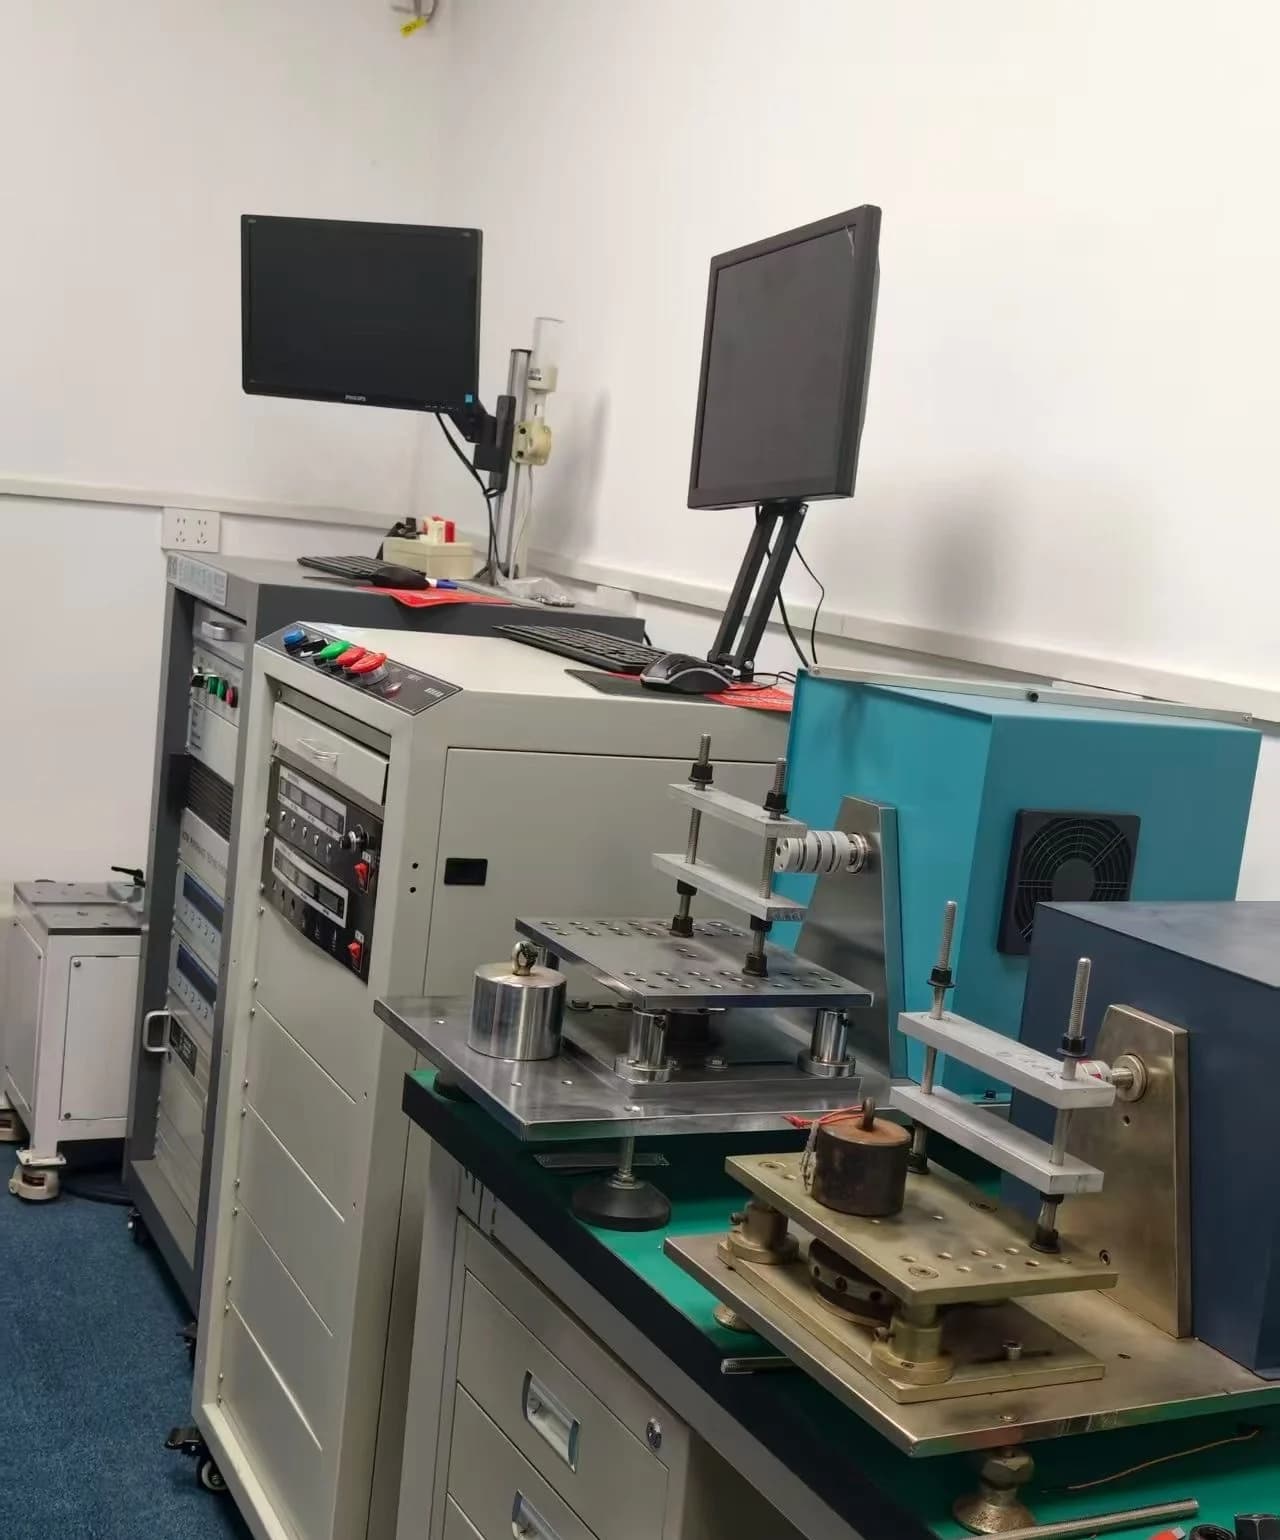
Prototype test-bench context: instruments, a monitor and a mechanical fixture.
Owner-provided prototype workbench photograph.
Prototype development
Agree the assembly interfaces, build revision and measurement conditions before the prototype is released. Use the results to define the next iteration and prepare the production configuration.
Explore the design-to-production path →Force & torque sensing
Compare force sensors, load cells, torque and multi-axis sensing around the actual load path. Define the mounting, cable, signal output and measurement records before choosing the configuration.
Select the sensor and its mechanical and electrical interfaces.
Define the sensor, cable, electronics and calibration scope together.
Agree interface changes, samples and acceptance work.
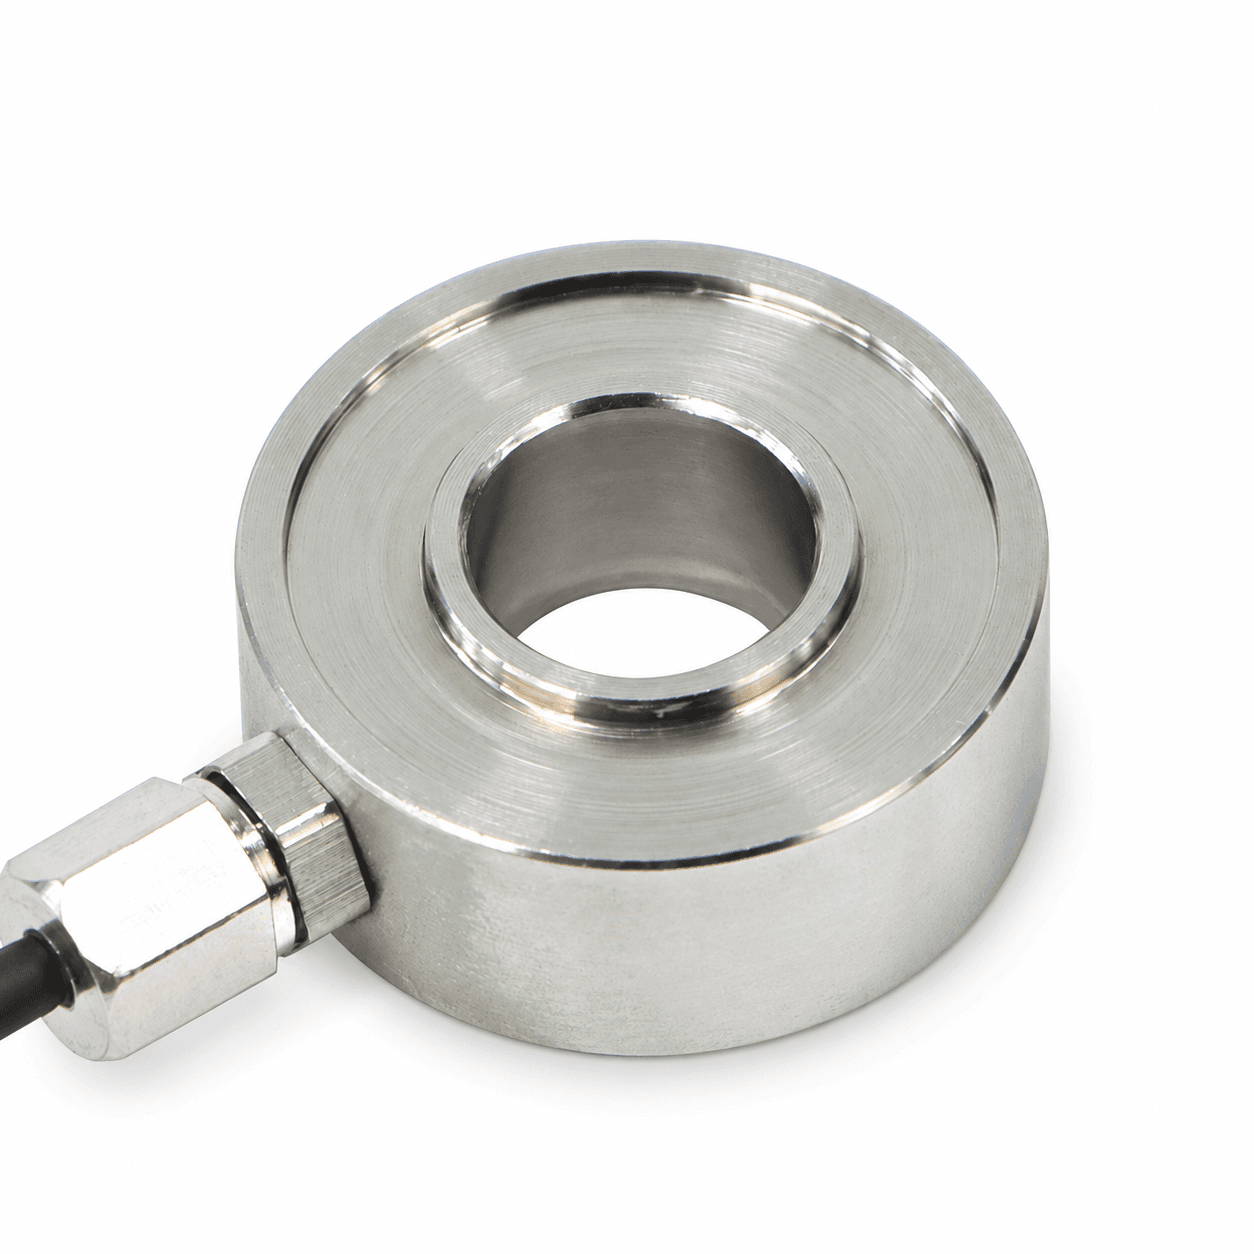
Through-hole compression load-cell form: review the loading face, bore and cable clearance.
Supplier-derived product-form reference from the owner’s sensor image library.
Actuator + sensor interface engineering
Bring your actuator drawing and force or torque measurement requirement. Define the mounting, load path, cable routing and signal interfaces with Magatom, then agree the prototype assembly and validation work for your application. Explore rotary torque sensing, linear load measurement and robot wrist sensor interfaces.
Discuss an Actuator–Sensor Assembly →Application-specific engineering
From precision tracking to demanding operating environments, bring your equipment, load cycle and interfaces. Build the motion, magnetic and feedback requirements into one application brief.
Payload inertia, direction changes and cable travel shape positioning performance.
Review the motor, transmission, output support and feedback interfaces around the required motion cycle.
Mechanical tracking must account for payload moments, disturbance loads and cable rotation.
Define the drive, bearings, feedback and control interfaces for the selected pointing architecture.
Pressure, contamination limits and heat paths constrain motion inside or across a chamber.
Review drive placement, materials, lubrication, wiring and feedthrough interfaces around the process requirements.
Exposure, service access and electronics placement shape the remote-handling mechanism.
Define the motion, feedback, insulation and cable requirements against the specified radiation environment and service cycle.
Water pressure, cable entries and corrosion shape the moving assembly's packaging.
Review the drive, housing boundary, feedthrough and sensing interfaces against depth, exposure and load requirements.
Temperature, shock and a narrow tool envelope constrain the complete drive.
Review magnetic materials, windings, transmission, bearings and feedback against the tool's operating cycle.
Friction, inertia and feedback response influence assistance and force-feedback development.
Compare drive, transmission and sensing interfaces for the required motion, evaluation stage and fault-response brief.
Load paths, mounting stiffness and sampling requirements shape force measurements.
Define fixture, sensor-mounting, overload and acquisition interfaces around the required loads and test sequence.
Surface gaps, curvature and weld transitions affect magnetic adhesion and traction on steel.
Review the magnetic contact assembly, geared drive, cable load and probe mount as one mechanical brief.
Assembly interfaces
Integration decisions cross component boundaries. Review the load cycle, package, mounting datums, feedback location, brake requirement, cable route and control interface together before selecting a baseline or releasing a prototype.
Start with published motor or actuator data and identify the changes needed for the application.
Connect mechanical, electrical and feedback requirements in one assembly brief.
Agree the build revision, measurement conditions and acceptance criteria before iterating.
Motion, sensing & magnetic components
Close the mechanical and control interfaces
Coordinate the motor or actuator with feedback, bearings, housing, brake, transmission, cabling, controls, and the customer-side mounting boundary.
Explore this capability →Turn electromagnetic design into motion
Match motor topology, electromagnetic loading, thermal path, feedback, mechanics, and controller limits to the complete operating cycle.
Explore this capability →Start from your duty, installation space or existing motor reference; plan design, prototype acceptance and pilot builds.
Connect the load to a usable measurement
Select the sensing direction, load path, mounting and signal chain for component supply, matched readout kits or a defined development project.
Explore this capability →Shape and control the field
Connect material, geometry, magnetization, air gap, return path, protection, and assembly choices to the field or force the application actually needs.
Explore this capability →Convert electrical input into force
Define the magnetic circuit, winding, drive, thermal path, moving interface, return behavior, and validation method as one actuation problem.
Explore this capability →Planetary & harmonic models
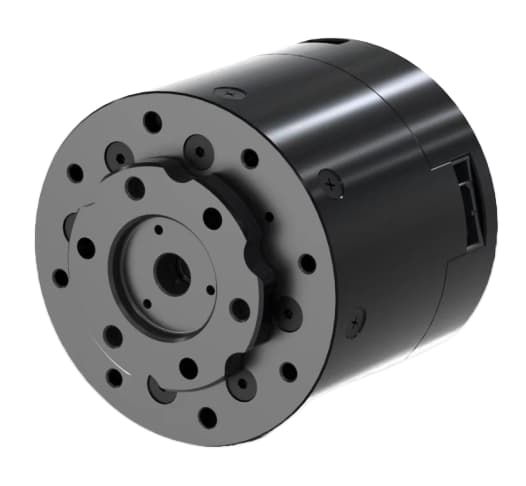
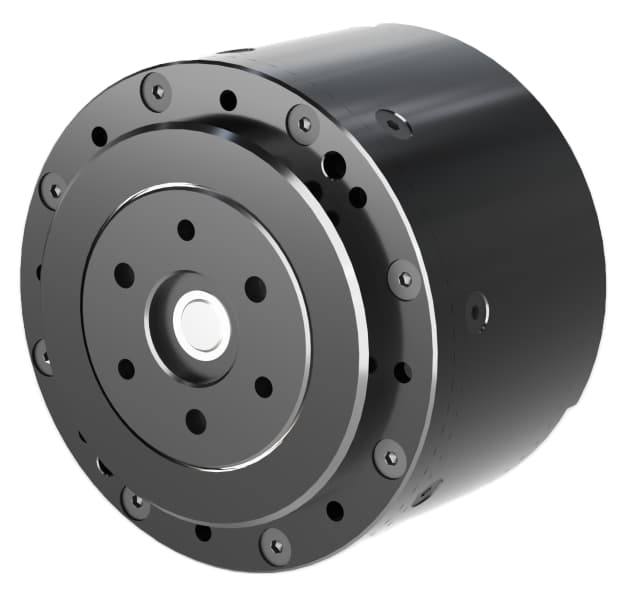
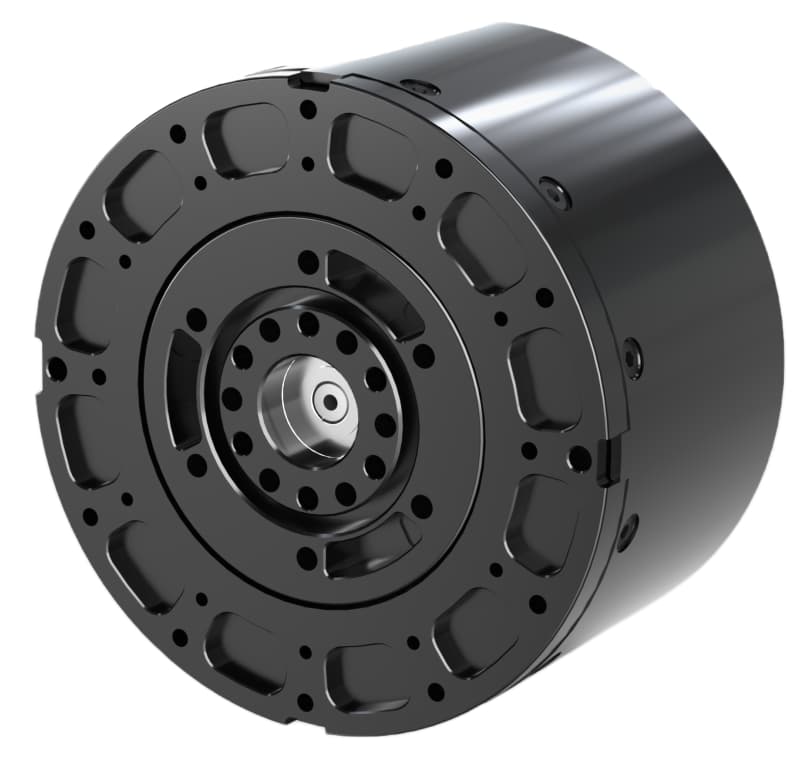
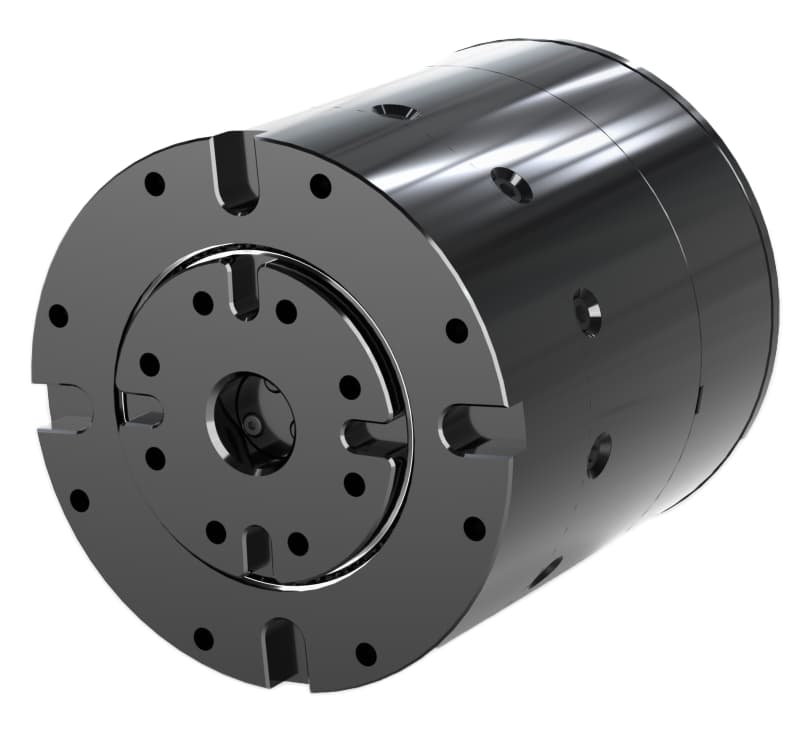
Compare 14 models by ratio, torque, speed, package and documented interfaces. Start with a catalogue baseline, then identify the configuration and integration requirements for your assembly.
Compare a 25:1 configuration at 6 Nm rated torque with a 5:1 configuration at 1.2 Nm rated torque.
Model 1 highlights
A 39:1 planetary model listing 25 Nm rated torque, 100 rpm peak speed and 1.2 Nm backdrive torque.
Model 1 highlights
Compare two 18:1 configurations, with brake customization available and no standard through-bore.
Model 1 highlights
A 100:1 harmonic model with 108 Nm rated torque and model-specific bore, brake and torque-sensor options.
Model 1 highlights
Project questions
Yes. Bring a sensor model or the load, mounting and signal requirements. Choose component supply or a matched sensor, cable and readout configuration; agree any calibration records and setup separately from custom development work.
Yes. Start with the published model and identify the changes needed in mounting, output, cabling, feedback or control. We review the configuration, interfaces and acceptance requirements together before agreeing the prototype scope.
Share the load cycle, installation envelope, mating interfaces, supply and control requirements, operating environment and project stage. A sketch and a list of open decisions are enough to start the brief.
Define the design direction, prototype revision and acceptance criteria first. Use the agreed tests to review each iteration, then plan pilot builds, production resources, documentation and repeat supply for the selected configuration.
All 14 actuator pages include their 2D outline and performance map. STEP files are available by email for MGA-PJ-60-10-39, MGA-PJ-100-20-10, MGA-PJ-105-27-18 and MGA-PJ-85-17-18. Ask us to check availability for another model.
Yes. Use an application brief to connect the motion, magnetic, mechanical and feedback requirements. You can bring selected components or leave the architecture open for comparison.
Your project plan identifies the configuration, performing parties, development work, acceptance records and production arrangements. Magatom provides one project contact through the application brief, prototype revisions and production planning.
Application & assembly review
Share the load cycle, installation envelope, mating interfaces, feedback and operating conditions. We can start from a published model, your selected components or an open architecture brief.
Bring a sketch, selected components or the open interface questions. Use the review to define the assembly scope and next development step.