Custom assembly engineering

Design, simulate, prototype, test and scale

Develop a motor, actuator-sensor or magnetic assembly from an application brief. Magatom connects design and simulation, rapid prototype iterations, agreed testing and production planning. Start with a drawing, a standard-model reference or the load and interface requirements that need to be resolved.

Explore Actuator + Sensor Integration →

Adapt a baseline

Begin with a published motor or actuator model. Identify the mounting, cable, feedback or duty requirements that need a focused configuration review.

Develop an assembly

Bring motor, transmission, magnetic components and mating parts into one interface brief. Compare the package, load path and electrical connections before a build.

Plan the next revision

Use prototype results to decide what changes and what stays fixed. Link the accepted drawing and configuration to pilot and volume-production planning.

From the brief to the build
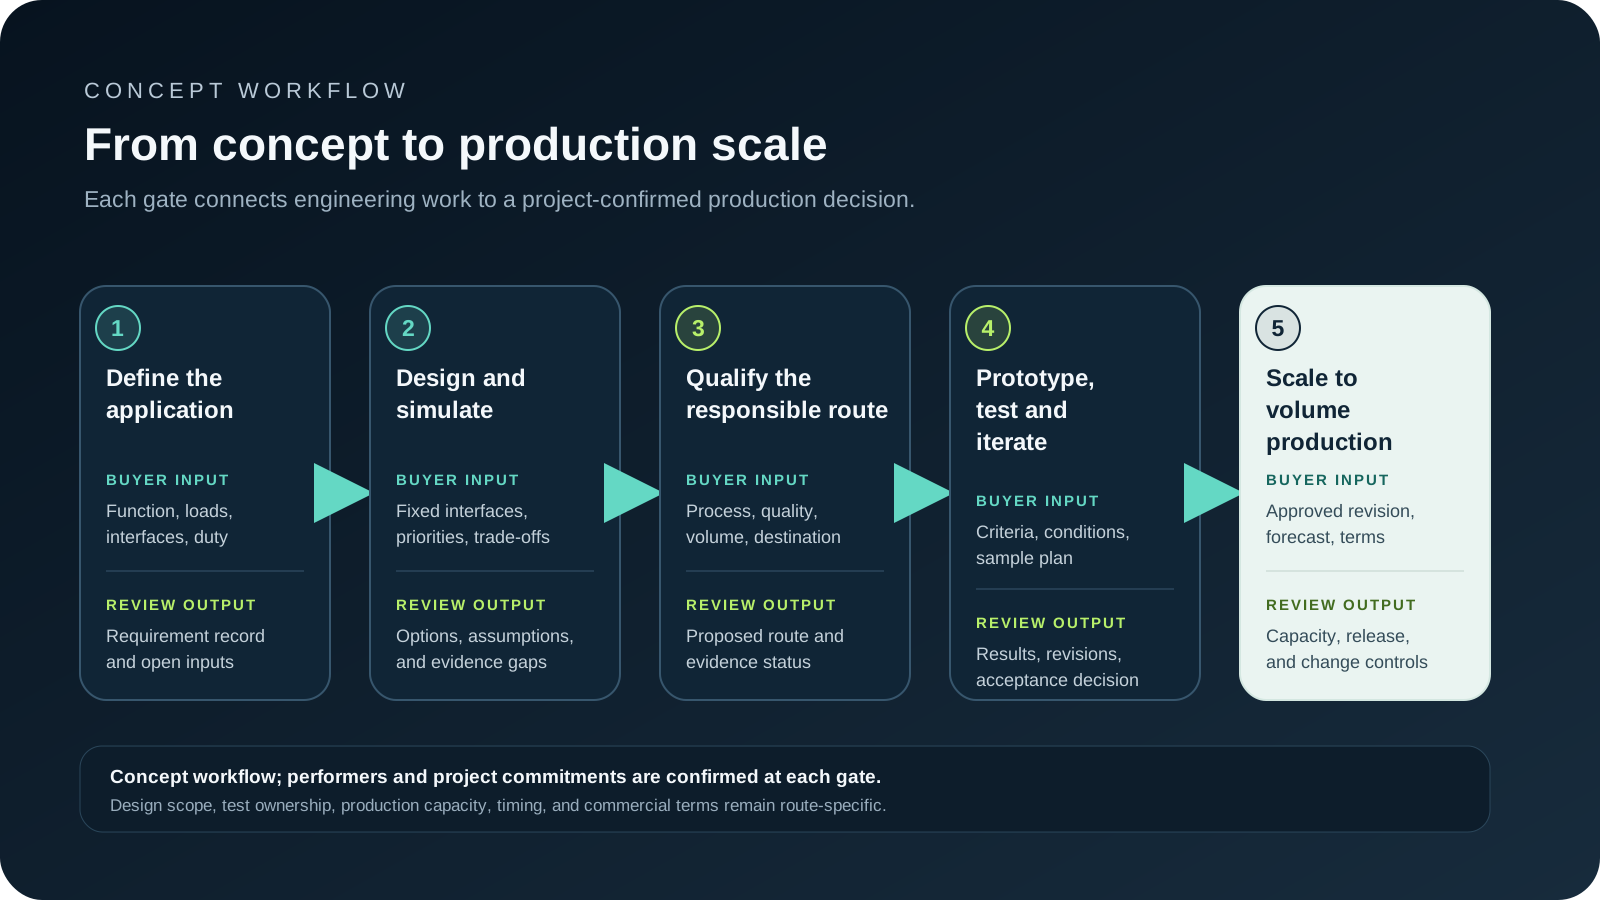
Define the output at each development stage

Five-stage project path covering requirements, design and simulation, production-route review, prototype iteration and production planning
Development workflow: define the brief, compare a design, review the build route, iterate prototypes and plan production.
  1. Stage 1

    Define the application

    Translate the equipment need into measurable field, force, motion, interface, environment, duty, and life requirements.

    Your starting inputs
    Application summary, drawings or envelope, operating points, constraints, failure concerns, quantity, and timing.
    Magatom project work
    Maintain one application brief and project record, and organize the design questions for review.
    Review output
    An application brief with target outputs, fixed interfaces, critical requirements and open decisions.
    Decision before the next stage
    The buyer confirms target outputs, fixed constraints, acceptance needs, and which inputs may remain open.

    For motor development

    A requirement brief, fixed interfaces, open decisions and acceptance objectives. Agree the operating cycle and which design questions the project must resolve.

  2. Stage 2

    Design and simulate feasible architectures

    Develop and compare architecture, material, geometry, winding, drive, retention, transmission, and protection directions. Use calculations or simulation where agreed to examine assumptions before prototype release.

    Your starting inputs
    Fixed interfaces, flexible choices, target priorities or cost target, incumbent reference if available, design inputs, and unacceptable trade-offs.
    Magatom project work
    Connect the design review with the technical parties and organize the agreed calculations or simulation, assumptions and interface decisions.
    Review output
    A reviewable design direction, interface decisions, and agreed analysis or simulation outputs with assumptions and unresolved risks.
    Decision before the next stage
    Select a design direction and the questions to check in the prototype. Record the analysis assumptions separately from measured test results.

    For motor development

    A candidate direction, drawing/interface decisions and agreed calculation or simulation assumptions and outputs. Select the candidate and prototype questions; keep predictions distinct from measured results.

  3. Stage 3

    Review manufacturability and the build route

    Prepare the design for a specialist production route by reviewing manufacturability, tooling, process assumptions, inspection access, documentation, capacity, and supply risk.

    Your starting inputs
    Required processes, compliance or documentation needs, volume range, timing, destination, quality expectations, and approved-source constraints.
    Magatom project work
    Review the proposed build with the specialist production parties, including processes, tooling, inspection access, capacity and documentation.
    Review output
    A build-route proposal identifying the responsible parties, manufacturability decisions, tooling and inspection requirements.
    Decision before the next stage
    Agree the performing parties, process scope, required records and open items before releasing the prototype build.

    For motor development

    A build route with process, retention, assembly, inspection-access and tooling decisions. Agree the prototype configuration, performing parties, cost items and required records.

  4. Stage 4

    Prototype, test, and iterate

    Coordinate prototype builds and rapid iteration loops against agreed acceptance criteria, then validate the released candidate under defined application conditions.

    Your starting inputs
    Prototype quantity, target iteration schedule, acceptance thresholds, test conditions, fixtures, measurement method, documentation, and system responsibility.
    Magatom project work
    Coordinate sample builds, design revisions, test planning, and results with the buyer and responsible project parties.
    Review output
    A controlled prototype and validation record linking each revision to test conditions, results, deviations, corrective actions, and acceptance decisions.
    Decision before the next stage
    Approve the design revision and acceptance record before pilot or volume-production release.

    For motor development

    Revision-identified samples, test conditions, results, deviations and the next iteration decision. Compare the measured candidate with the acceptance targets before releasing the next revision.

  5. Stage 5

    Scale to volume production

    Move an accepted design from pilot into planned production volume with a controlled revision, quality plan, change process, packaging, and repeat-supply boundary.

    Your starting inputs
    Approved drawing/specification, target production volume and ramp, forecast or order quantity, destination, packaging needs, quality records, and change authority.
    Magatom project work
    Own the project and revision record; coordinate route capacity confirmation, approved documents, quality and change controls, packaging, and supply handoff.
    Review output
    A project-specific pilot-to-volume release plan and repeat-supply boundary with capacity status, approved evidence, responsibilities, change rules, and commercial commitments.
    Decision before the next stage
    The buyer and responsible route owner approve the released revision, production capacity and quality plan, acceptance records, change authority, and commercial terms.

    For motor development

    An accepted design revision, inspection/test plan, tooling/process documents and production-ramp proposal. Agree pilot quantity, quality records, change control and production arrangements.
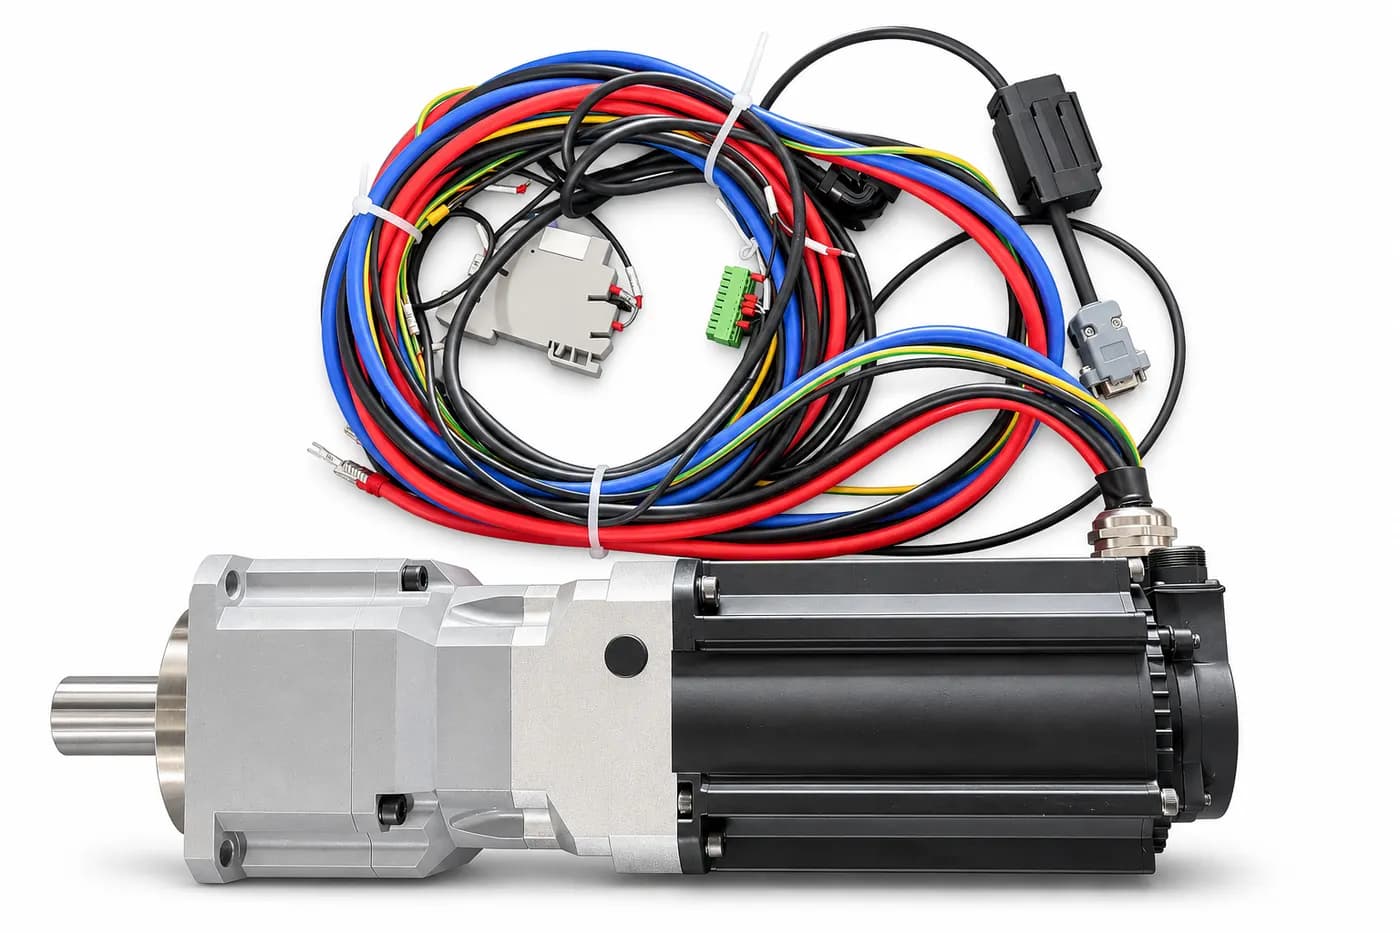
Silver planetary gearbox mated to a black servo motor with output shaft, motor connectors and coiled matching cable harness on white

Geared servo assembly with matched power, feedback and brake wiring.

Product view prepared from the project photograph.

48V geared servo packages

From motor and gearbox to a matched servo package

Review the motor, planetary gearbox, holding brake, external drive and wiring as one defined supply package. Start from a reference build or bring the load cycle and interfaces your machine needs.

Custom permanent-magnet motor development

Move from a motor requirement to a prototype plan

Define the motor duty, stator-rotor envelope or current motor reference, then agree the design, assembly and validation work needed for the next revision.

Define motor development, tooling, samples and testing separately from the production quotation, with quantities and timing linked to the agreed work.

Prototype and test planning

Put the fixture, interfaces and measurements into the build plan

Plan how the prototype mounts, how it is driven and which measurements answer the design questions. Define the test conditions, responsible operator and acceptance record for each revision.
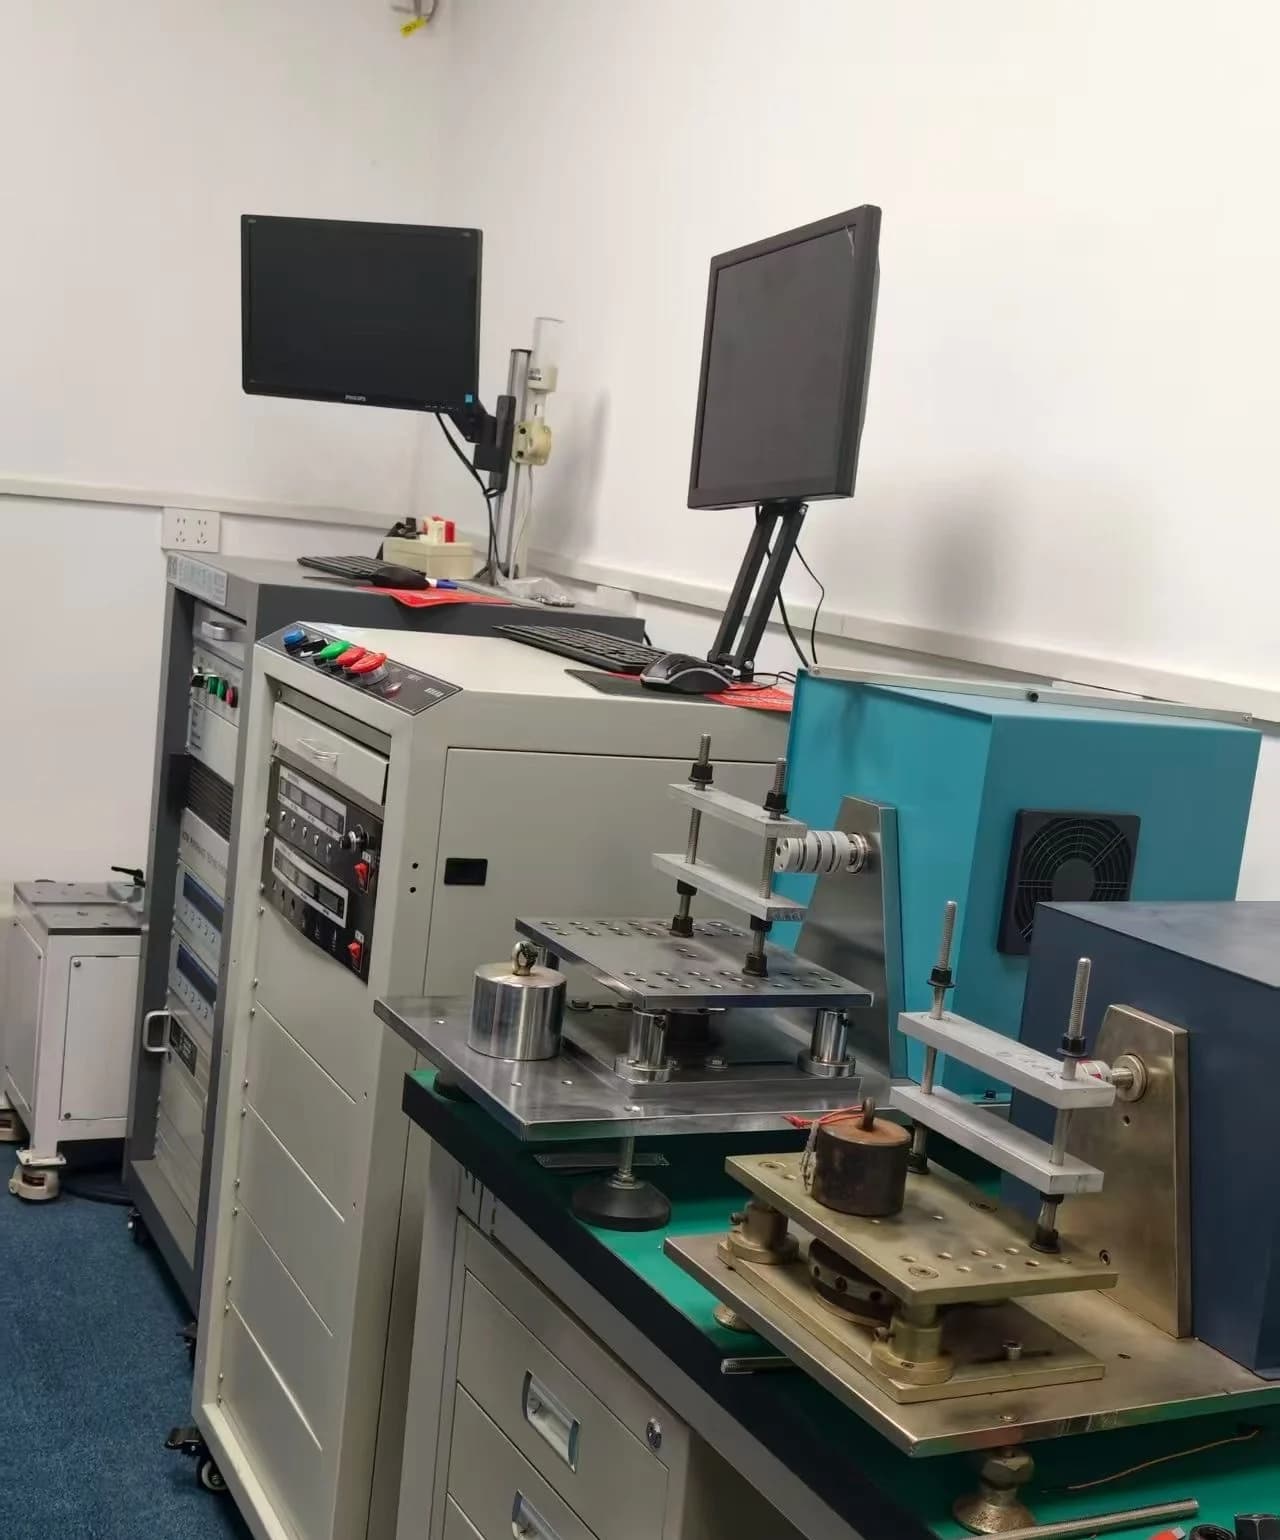
Prototype test-room workbench with instruments, a monitor, and a mechanical fixture

Prototype test-bench context: instruments, a monitor and a mechanical fixture.

Owner-provided prototype workbench photograph.
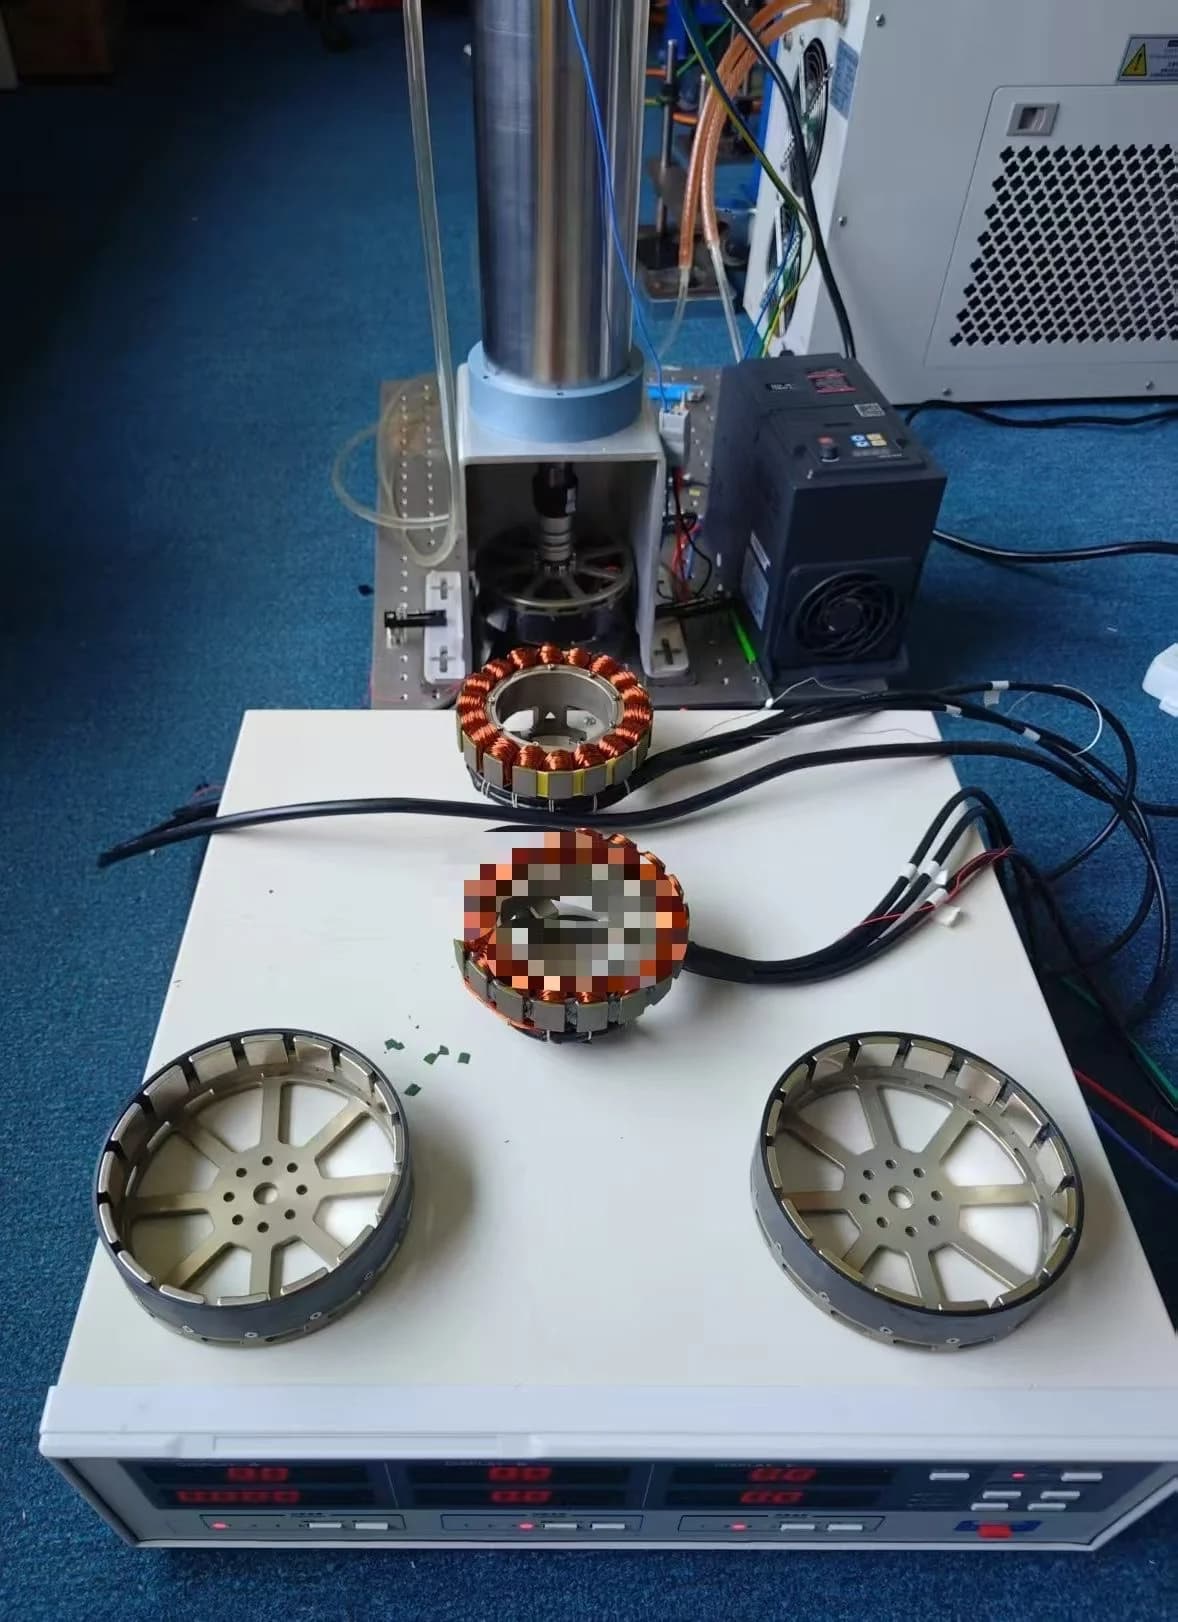
Circular motor assemblies and a test fixture on a bench, with central sample areas remaining pixelated

Motor prototype setup context, with pixelated sample details retained.

Owner-provided prototype setup photograph; sample pixelation retained.

Motion + measurement · Custom development

Actuator + Force/Torque Sensor Integration for OEM Equipment

Develop the mechanical and measurement interfaces around your equipment. Start with selected components or an open requirement, then define the assembly scope, control interfaces and acceptance plan before releasing a prototype.

Rotary actuator with torque sensor

For rotary test rigs, instrumented joints and mechanisms that need a defined torque measurement point.

Mechanical measurement path

  1. 1Actuator output
  2. 2Adapter + torque sensor
  3. 3Driven load

Drive interfaceCommand + motor feedback ↔ controller

Measurement interfaceSensor → conditioner / readout → receiving system

Concept interface map · numbered blocks show the proposed mechanical sequence; drive and measurement signals are defined separately. Review supports, load bypasses and the actual configuration in the project drawing. Original Magatom editorial diagram.
What is measured
Locate the sensing element relative to the motor, gearbox and payload. An output-side sensor measures torque transmitted through its own load path; motor current estimates torque at a different point in the drive chain.
Interfaces to resolve
Review the actual drawings, pilot and bolt pattern, support bearings, permitted side loads, torsional stiffness and overloads. Define stationary reaction sensing or rotating measurement, cable travel and signal transfer for the intended motion.
Prototype acceptance
Agree mounting and fastener conditions, load direction, zero/preload, reference loads and checks with the motor operating. Record the configuration and conditions covered by the measurement results.
Discuss Rotary Torque Sensing

Linear actuator with load cell

For axial load monitoring in joining fixtures, tension/compression tests and linear mechanisms.

Mechanical measurement path

  1. 1Actuator rod / carriage
  2. 2Axial load cell + mount
  3. 3Fixture / workpiece

Drive interfaceCommand + motor feedback ↔ controller

Measurement interfaceSensor → conditioner / readout → receiving system

Concept interface map · numbered blocks show the proposed mechanical sequence; drive and measurement signals are defined separately. Review supports, load bypasses and the actual configuration in the project drawing. Original Magatom editorial diagram.
What is measured
A linear actuator with a force sensor can measure the load transmitted to the fixture. Choose the measurement location and intended force axis before selecting a rod-end, inline or through-hole load-cell arrangement.
Interfaces to resolve
Define rod threads or carriage interfaces, tension/compression, stroke, speed, preload and external guidance. Check bending, side loads, buckling and any load that bypasses the sensor through guides or other supports.
Prototype acceptance
Agree the mounting, reference loading, zero/tare, signal scaling and overload checks. For force–displacement monitoring, also define how position and force are acquired and aligned in time.
Discuss Linear Force Measurement

Robot wrist force/torque sensor integration

For end-of-arm tooling, grippers and quick-change assemblies that need multi-axis load measurement.

Mechanical measurement path

  1. 1Robot wrist flange
  2. 2Adapter + 6-axis F/T sensor
  3. 3Tool / quick changer

Drive interfaceCommand + motor feedback ↔ controller

Measurement interfaceSensor → conditioner / readout → receiving system

Concept interface map · numbered blocks show the proposed mechanical sequence; drive and measurement signals are defined separately. Review supports, load bypasses and the actual configuration in the project drawing. Original Magatom editorial diagram.
What is measured
Define the forces and moments at the sensor coordinate frame, then relate them to the tool contact point. Include the mass, center of gravity and inertia of every component mounted beyond the sensor.
Interfaces to resolve
Specify the exact robot model, robot-side and tool-side flange drawings, combined loading, payload allowance and cable clearance. Identify the complete ISO 9409-1 pattern where applicable; a standards reference alone does not define the two mating interfaces.
Prototype acceptance
Agree mounting, tool-frame transformation, tare/gravity compensation and cable-reaction checks. Define the robot controller, receiving interface and software configuration needed to use the measurements.
Discuss Wrist Sensor Integration

Agree the interfaces and prototype outputs

Mechanical package
Interface drawings, datums, load path, bearing/support arrangement, adapter design and assembly method.
Measurement chain
Named sensor, cable and readout configuration; units, scaling, range and the applicable calibration boundary.
Controller handoff
Separate actuator and sensor interfaces, defined for your controller. Agree wiring, pinout, data format, timing and the software/commissioning scope with the project brief.
Prototype acceptance
Drawing and build revision, responsible parties, inspection and test conditions, measurement records and the decision before the next build.

Bring the actuator and sensor drawings or references, required loads and duty, available space, receiving controller and prototype quantity. Review sensor-body or mounting changes with the responsible manufacturer or engineer and agree the validation and calibration needed for the proposed configuration.

Position Feedback, Torque Estimates and Load Measurement

Position encoder
Where is the mechanism, and how is it moving?
Define: Encoder location, resolution, actual accuracy, interface and the mechanical/control arrangement.
Motor current and torque estimate
What torque does the drive estimate under these conditions?
Define: Motor model, transmission, friction/losses and the duty over which the estimate is evaluated.
Force or torque at a defined load path
What load passes through this sensing location?
Define: Load introduction, mounting/support, range, signal chain and calibration conditions.
Multi-axis force/torque
Which forces and moments act at this reference frame?
Define: Combined loading, coordinate transformation, tare/gravity handling and the receiving controller.

Resolution describes measurement increments; accuracy describes how closely a measurement matches the actual position. Output-side position feedback can help control a mechanism, while the transmission retains its physical clearances and compliance. A characterized elastic element with position sensing can also report torque from its calibrated deflection.

Define how your controller will use the feedback: signal format, units and scaling, update timing, filtering, software configuration and commissioning. Agree these outputs with the assembly and test scope.

Start with the supply scope you need

Buy a standalone actuator or sensor, specify a matched sensor/readout kit, or define an assembly-development project. Bring an existing actuator model as a reference when the integration starts from a standard component.

Standard model to application brief

Compare an actuator baseline before commissioning a new design

Explore 14 planetary and harmonic models by ratio, rated torque, speed and interfaces. Share an incumbent reference and cost target when available. Compare mounting, control, operating conditions and the complete configuration to define any changes needed.

Compare Actuator Models

Agree the build and acceptance scope

  • Application targets, mounting datums and critical interfaces
  • Design revision, materials, configuration and prototype quantity
  • Test conditions, fixtures, measurement method and acceptance thresholds
  • Responsible engineering, production and test parties named in the project plan

Prepare the pilot and production handoff

  • Accepted drawing, configuration and required documentation
  • Tooling, production route, capacity and quantity ramp
  • Inspection, packaging, change authority and repeat-order records
  • Quotation scope, timing, delivery terms and purchasing responsibilities

Plan your development project

Design, prototype and production questions

What should we send for a custom assembly review?

Send the function, load cycle or magnetic objective, installation envelope, mounting and electrical interfaces, environment and project stage. Include drawings, a baseline model or incumbent reference, quantity range, timing and cost priorities when available.

How are design and simulation used before prototyping?

Agree the design questions, assumptions and outputs to review. Calculations or simulation can compare candidate directions before a prototype is released. The prototype test plan then checks the selected design under defined loads and conditions.

How do we plan rapid prototype iterations?

Choose the first build revision, prototype quantity, critical interfaces and acceptance criteria. Agree the build and test schedule with the responsible parties, then link each change to a revision and review the measured results before the next build.

Can we adapt a standard actuator instead of starting from zero?

Compare the published model with the required torque-speed cycle and interfaces first. Identify the listed options or changes to review, then confirm the configuration, drawing and applicable limits for quotation.

What is agreed before pilot or volume production?

The release plan identifies the accepted drawing and configuration, performing parties, tooling, inspection and acceptance records, production capacity, packaging, change authority and commercial terms. The quantity and ramp schedule belong to that project plan.

Develop the application interfaces

Use these engineering guides to connect the component requirements with the equipment, mounting and evaluation brief.

Application & assembly review

Define the next design or prototype decision

Send the application, drawing or envelope, load cycle, fixed interfaces and open questions. Include the prototype stage, test priorities and expected production volume.

Bring a sketch, selected components or the open interface questions. Use the review to define the assembly scope and next development step.