01 · Screen the duty
Match torque and speed over time
Compare rated and peak values with the actual motion profile, including peak duration, repetition, acceleration, and thermal conditions. Do not size from peak torque alone.
Integrated harmonic rotary actuator · Model 1 highlights
Review a 100:1 harmonic reduction with Model 1 values of 108 Nm rated torque, 304 Nm under “Peak torque (>3 s),” 62 rpm peak speed and 1,600 g mass. Through-bore, brake and torque-sensor customization can be discussed for this model. Define the required option combination and request its resulting drawing and limits.
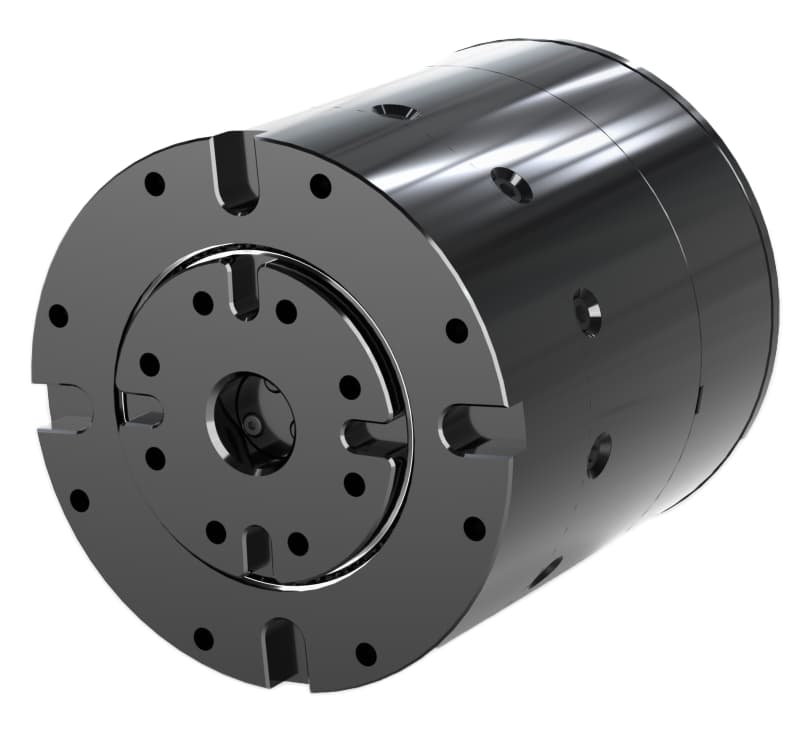
Model 1 summary
These highlights describe Model 1. Compare the configuration tables below with the load cycle, mounting and controller requirements.
Start with the listed harmonic configuration and its model-specific options. Describe the interface or function that needs to change so the build, drawing and applicable limits can be reviewed together.
Describe the interface or function you would like to adjust, along with the application requirements. We can check whether a listed option or another configuration is available for this model. The exact build, drawing, and applicable limits need confirmation before an order.
The listed build is Model 1. Request a configuration review if the duty or interfaces need to change. Unspecified cells are marked “Not specified.”
| Parameter | Unit | Model 1 | Model 2 |
|---|---|---|---|
| Operating voltage | V | 12-72 | Not specified |
| Rated voltage | V | 48 | Not specified |
| Rated torque | Nm | 108 | Not specified |
| Rated speed | RPM | 46 | Not specified |
| Rated current | A(rms) | 14.5 | Not specified |
| Peak torque (>3 s) | Nm | 304 | Not specified |
| Peak speed | RPM | 62 | Not specified |
| Peak current | A(rms) | 60 | Not specified |
| Torque constant | Nm/A | 7.45 | Not specified |
| Back-EMF constant | Vrms/Krpm | Not specified | Not specified |
| Speed constant | rpm/V | 1.3 | Not specified |
| Motor constant | Nm/√W | Not specified | Not specified |
| Electromechanical time constant | ms | Not specified | Not specified |
| Electrical time constant | ms | Not specified | Not specified |
| Pole pairs | — | 21 | Not specified |
| Winding connection | — | Star | Not specified |
| Phase resistance | Ω | 0.2 | Not specified |
| Phase inductance | mH | 0.1 | Not specified |
| Parameter | Unit | Model 1 | Model 2 |
|---|---|---|---|
| Reduction ratio | — | 100 | Not specified |
| Reducer backlash | Arcsec | 20 | Not specified |
| Output bearing | — | Crossed-roller bearing | Not specified |
| Backdrive torque | Nm | Not specified | Not specified |
| Rotational inertia | g.cm² | Not specified | Not specified |
| Weight | g | 1600 | Not specified |
| Axial load | kN | 16.3 | Not specified |
| Radial load | kN | 7.2 | Not specified |
| Parameter | Unit | Model 1 | Model 2 |
|---|---|---|---|
| Control bandwidth | Hz | 2000 | Not specified |
| Communication | — | CAN | Not specified |
| Encoder type | — | Mechanical dual encoder | Not specified |
| Encoder resolution | bit | 14 | Not specified |
| CAN interface | — | XT30(2+2)PB-M | Not specified |
| USB interface | — | SH1.0-4P | Not specified |
| Power interface | — | XT30(2+2)PB-M | Not specified |
| Control modes | — | Servo mode; Speed mode; Torque mode; Force-position hybrid mode | Not specified |
| Protection functions | — | Overvoltage protection; Overcurrent protection; Overtemperature protection | Not specified |
| Parameter | Unit | Model 1 | Model 2 |
|---|---|---|---|
| Duty type | — | S2 | Not specified |
| Ingress protection | — | IP40 | Not specified |
| Cooling method | — | IC410 | Not specified |
| Ambient operating temperature | — | -20℃~50℃ | Not specified |
| Insulation class | — | F | Not specified |
| Dielectric strength | — | 500V 1kHz 1A 1ms | Not specified |
| Insulation resistance | — | 100MΩ 20℃ | Not specified |
| Noise | — | 60dB/1.0m | Not specified |
| Temperature sensor | — | NTC MF52B 103F3950 | Not specified |
All data are provided for U= 48 V and T= 25°C, unless otherwise specified. Specifications for different voltage levels or other operating limits, and corresponding simulation models, are available upon request.
Send it with the duty cycle and controller requirements for a model-specific engineering review.
01 · Screen the duty
Compare rated and peak values with the actual motion profile, including peak duration, repetition, acceleration, and thermal conditions. Do not size from peak torque alone.
02 · Check interfaces
Compare the original drawing with the mating parts, loads, cable route, connectors, supply, communication protocol, and feedback requirements.
03 · Confirm the build
Confirm the selected Model 1/Model 2 configuration, current drawing revision, option content, test conditions, and validation evidence before freezing a design.
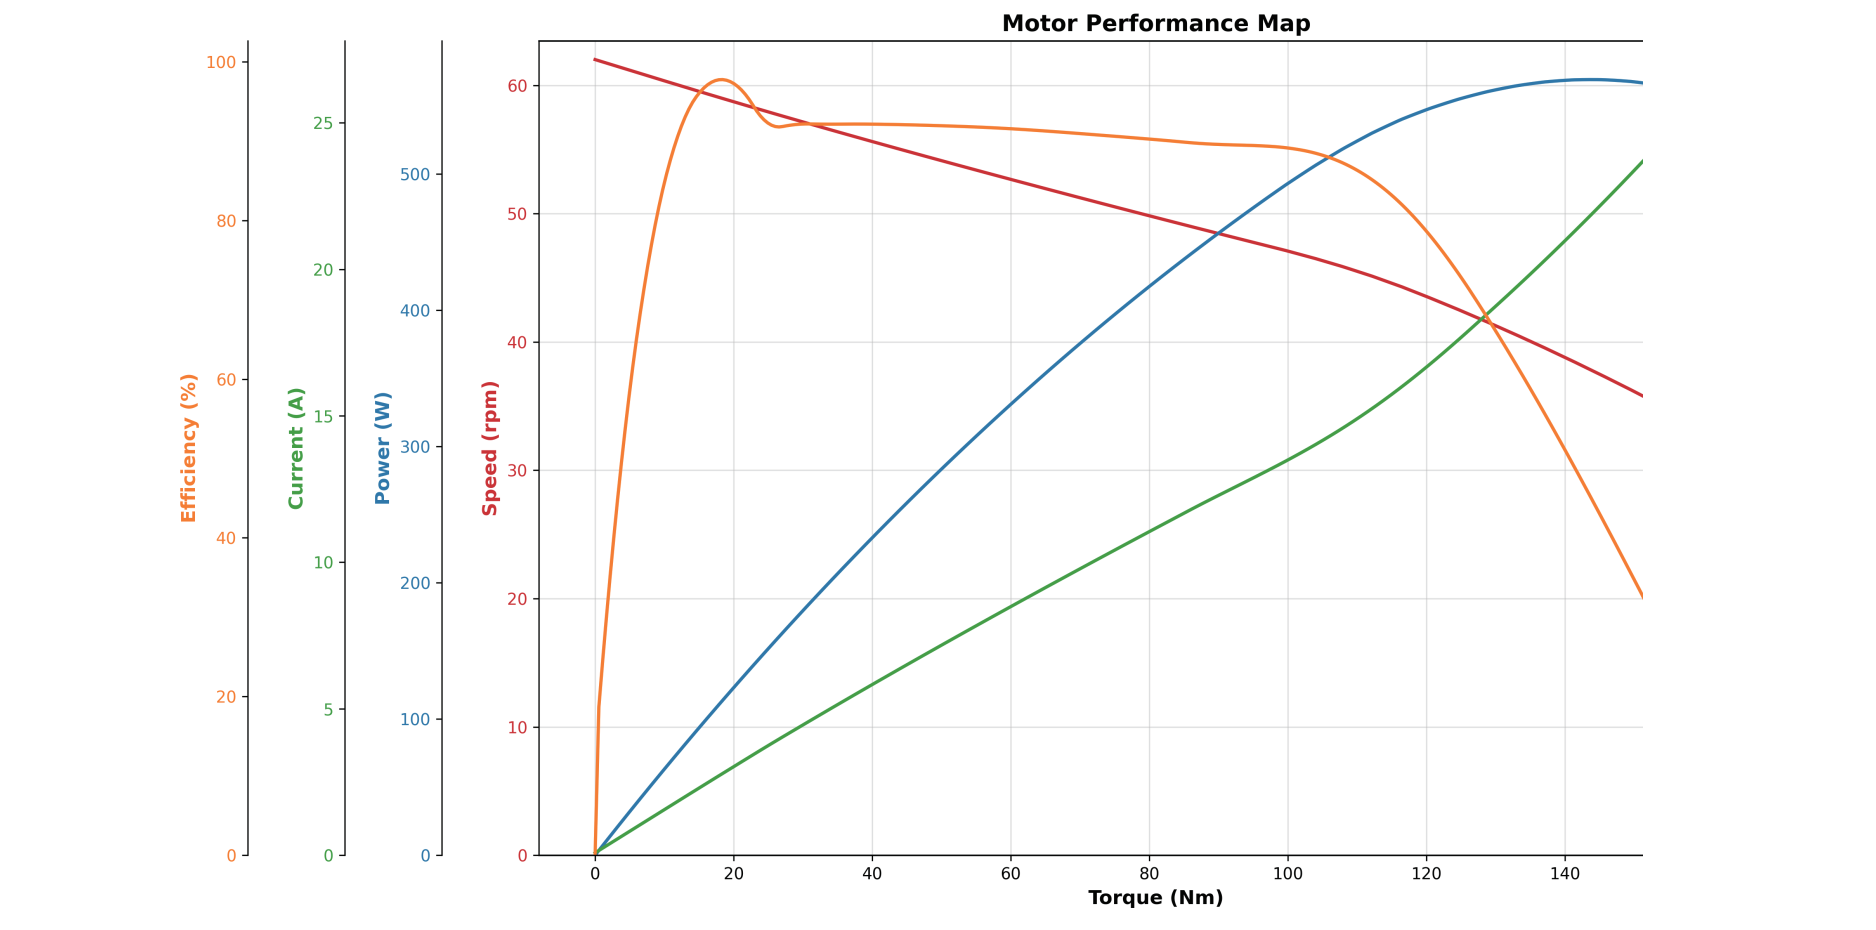
Check mounting and cable clearances in the original 2D drawing. Review the torque, speed, power, current and efficiency map with the selected configuration; confirm curve identities and test conditions before using it for controller or thermal sizing. Open either image for a larger view.
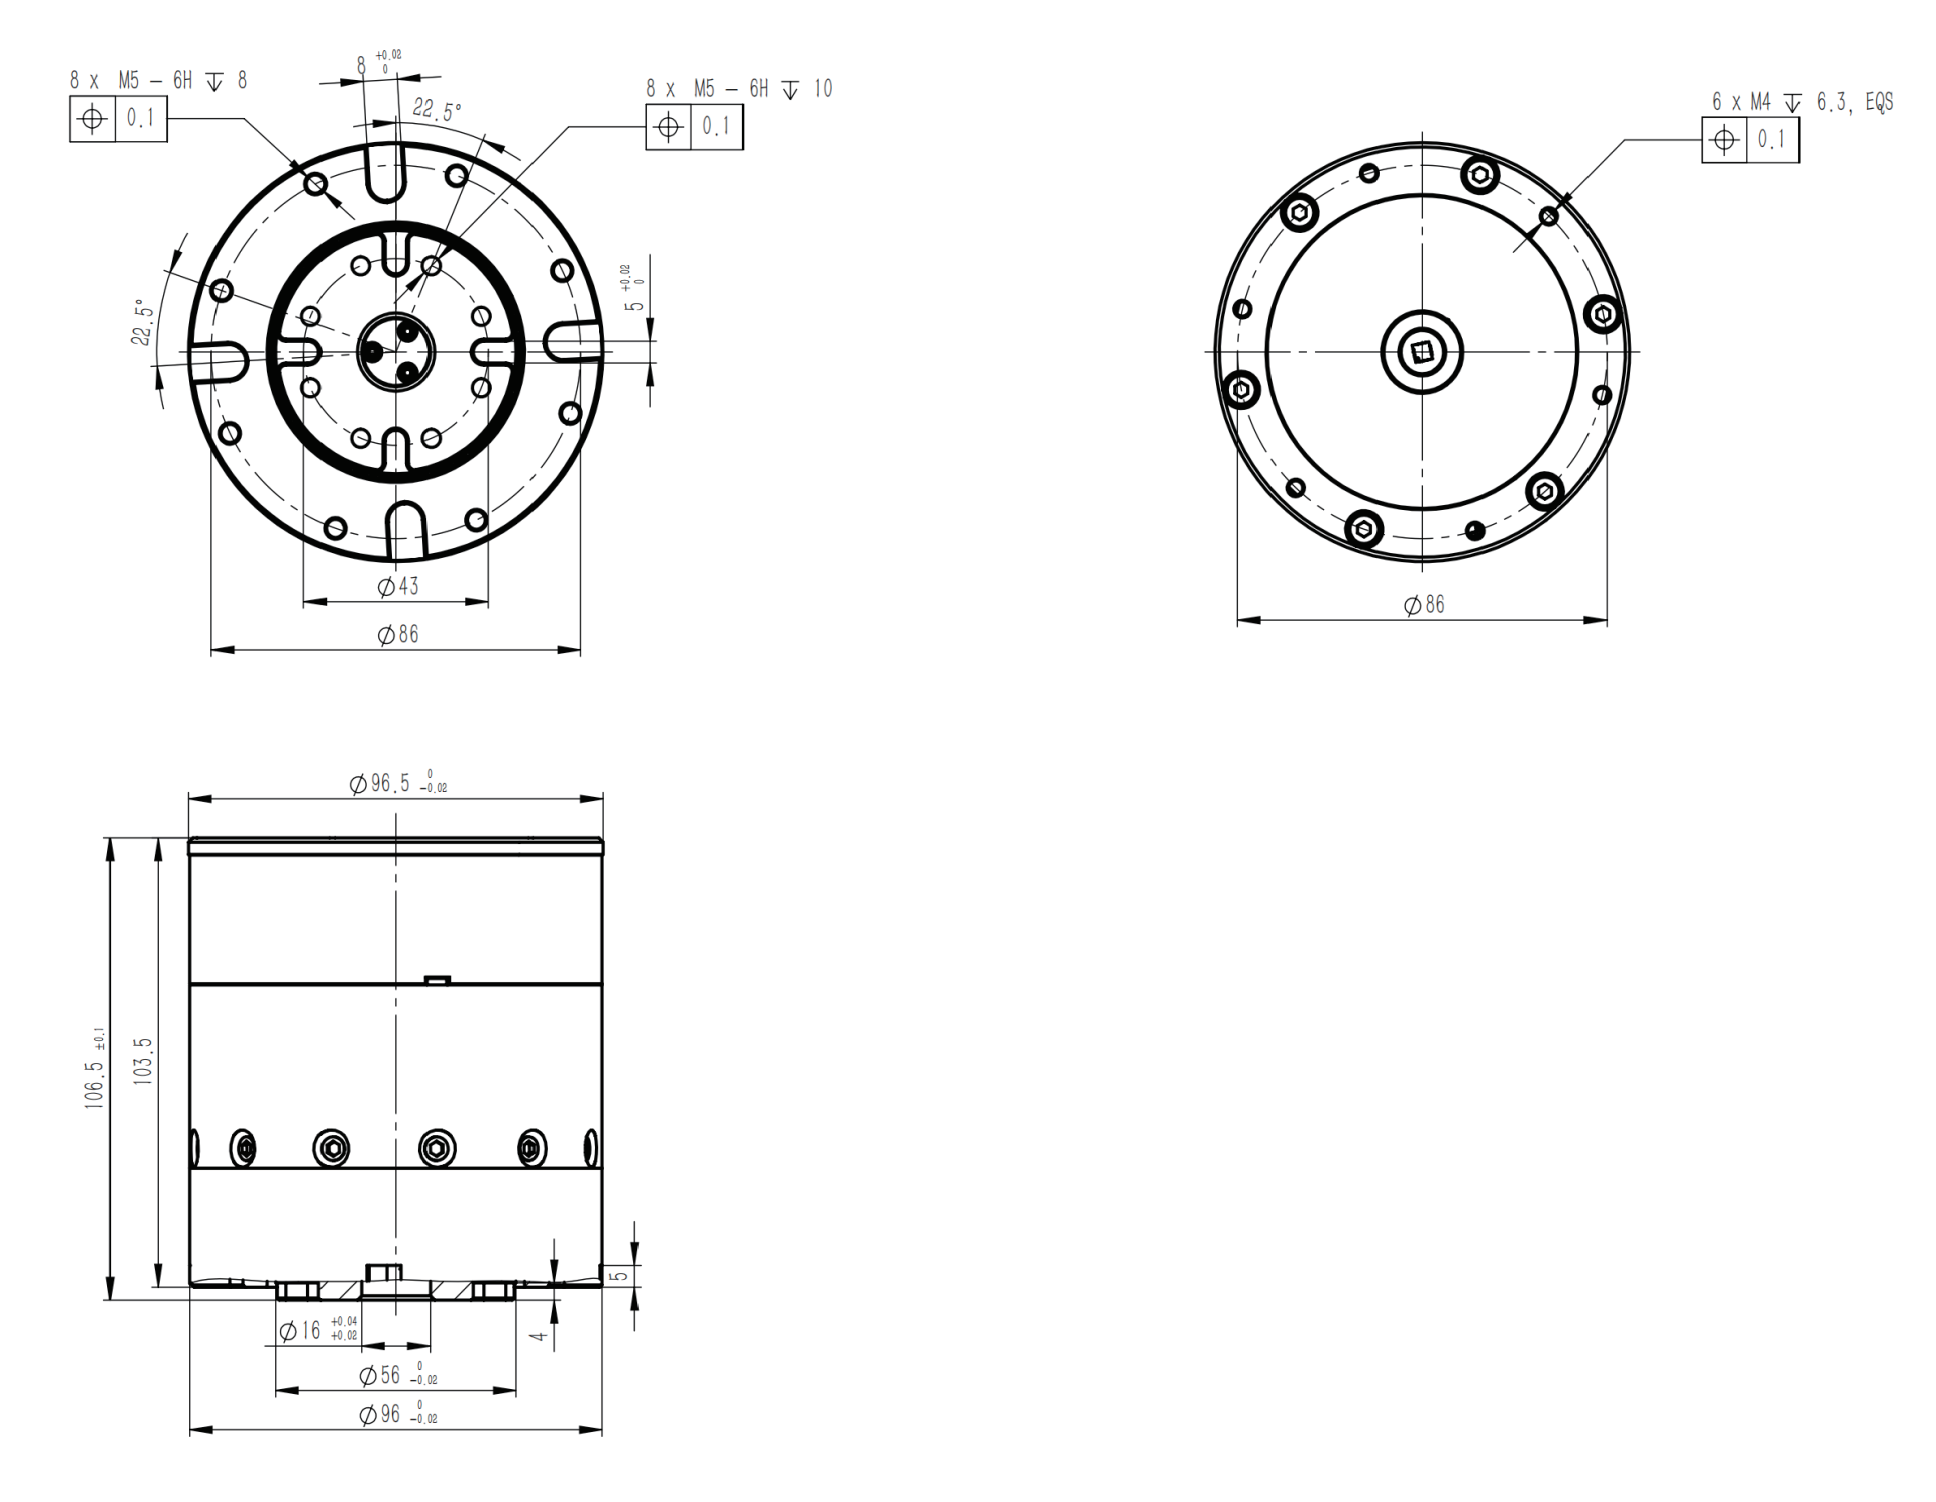
STEP availability is not confirmed for this model. Email us with the public SKU and requested configuration so we can check.
Compare the rated duty, ratio and interfaces of these related models before choosing a configuration for quotation.
Planetary · Model 1
60 Nm rated torque · 300 Nm peak torque · 18:1 ratio
Compare Model SpecificationsPlanetary · Model 1
80 Nm rated torque · 400 Nm peak torque · 18:1 ratio
Compare Model SpecificationsPlanetary · Model 1
40 Nm rated torque · 170 Nm peak torque · 10:1 ratio
Compare Model SpecificationsConnect the published specifications with your mechanism. Share the fixed interfaces and open design questions so the next review can focus on the required configuration and prototype decisions.
Use MGA-HJ-80-100 as the actuator reference for an output-torque sensing review. Define the sensor location, load path, bearing support, mounting and readout before selecting the combined configuration.
Identify the required combination, mounting envelope, cable path, holding requirement and torque-feedback interface. Request the resulting drawing and rated limits for that configuration. These are model-specific customization directions rather than one defined standard option package.
Dual encoders provide motion feedback. Check their locations and interfaces for the selected configuration. A separate output-torque measurement needs its own sensor arrangement, load path and applicable calibration records. An engineered elastic element with position sensing can also measure torque; the label “dual encoder” alone does not establish that design.
Model 1 lists 14 bit encoder resolution. Resolution describes measurement increments. Installed positioning accuracy also depends on encoder performance, mounting, the transmission and control system. Use the configuration and conditions of a position test rather than interpreting a bit count as an angular-accuracy guarantee.
This model lists torque-sensor customization. Use MGA-HJ-80-100 as the actuator reference and share the required torque measurement point, mounting drawing, operating loads and readout. Review the combined mechanical and measurement configuration as a development project, with its sensor, mounting and acceptance scope defined together.
Model 1 lists 108 Nm rated torque and 304 Nm under “Peak torque (>3 s),” with 46 RPM rated speed and 62 RPM peak speed. Check the torque-speed profile and repetition of each load against the operating conditions below. These figures are separate parameters, not a simultaneous operating point.
The specifications describe Model 1. Model 2 cells are unspecified; request a separate configuration review if the listed build needs to change.
Send torque and speed over time, peak duration and repetition, acceleration, dwell and cooling conditions. Include mounting loads and the controller interface so the rated and peak values can be reviewed against the complete cycle.
Use the map to frame the torque, speed, power, current and efficiency review. Request confirmation of the curve identities, configuration and test conditions before using a curve for controller or thermal sizing.
Application & assembly review
Share the torque-speed cycle, peak duration, mounting drawing and controller requirements. Include the prototype stage, quantity range and acceptance priorities to define the next configuration review.
Bring a sketch, selected components or the open interface questions. Use the review to define the assembly scope and next development step.