Available direction

Motion modules · Model-level data

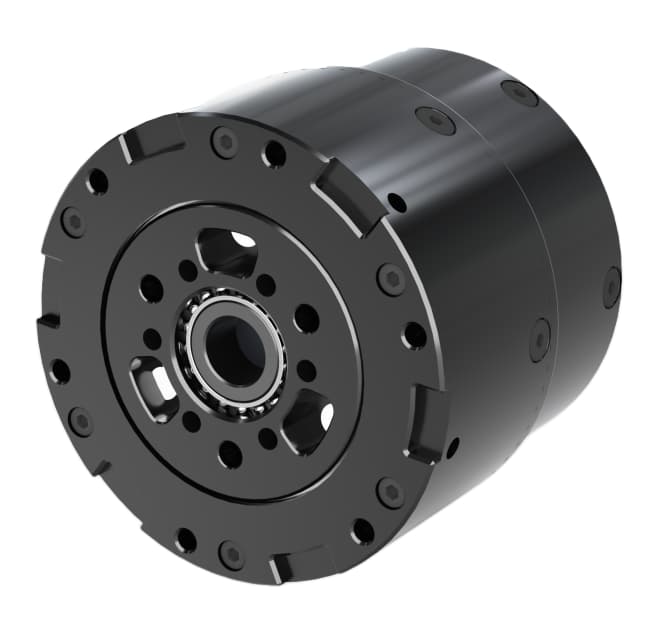
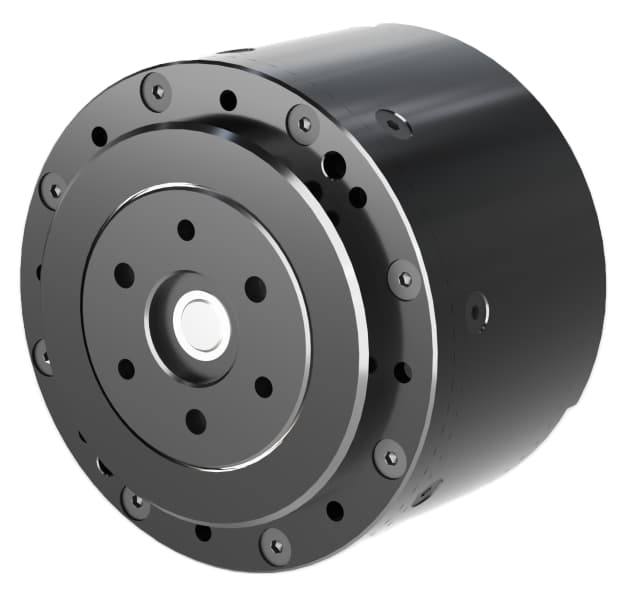
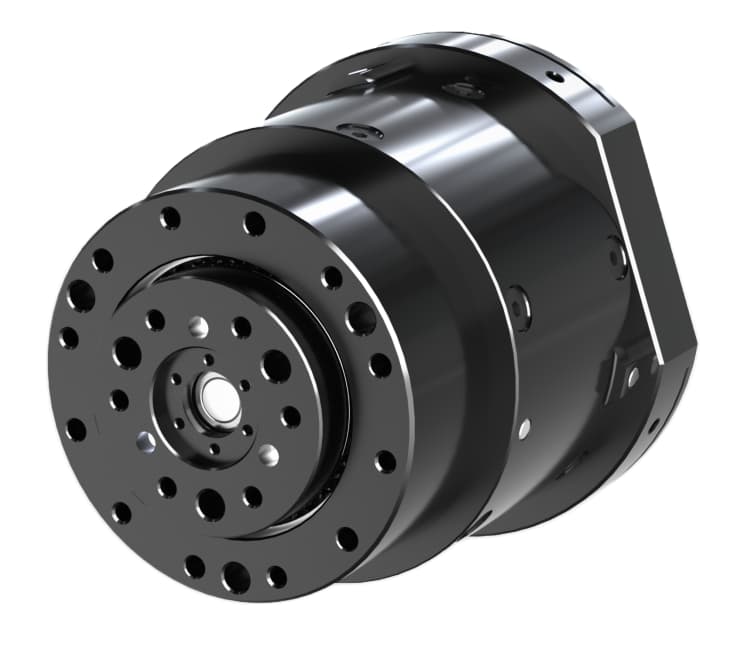
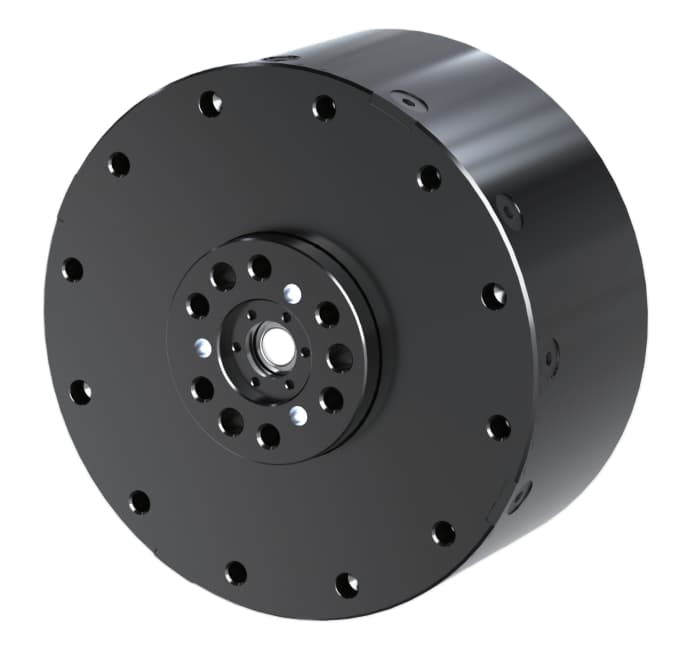
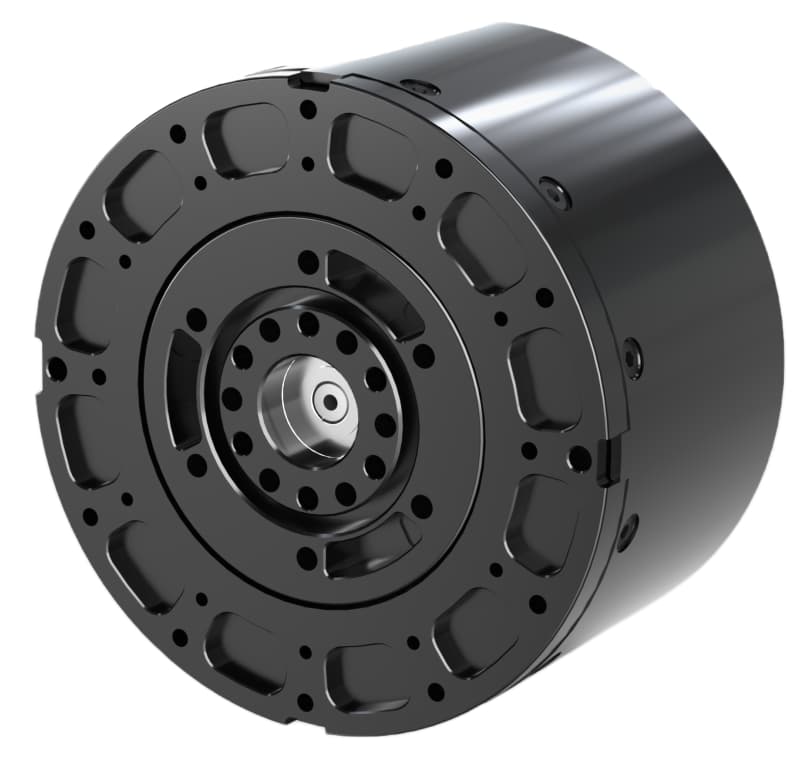
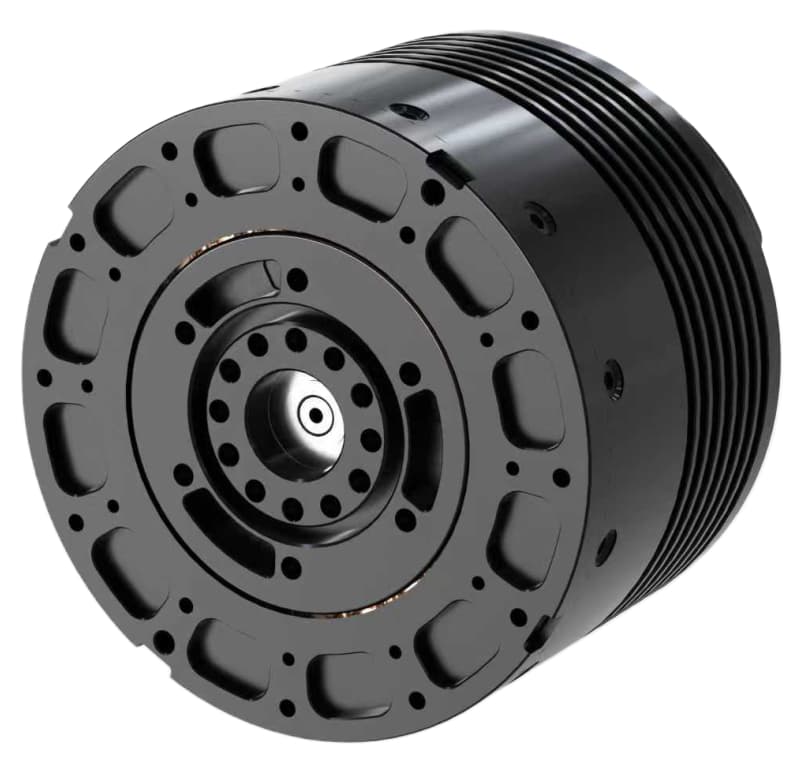
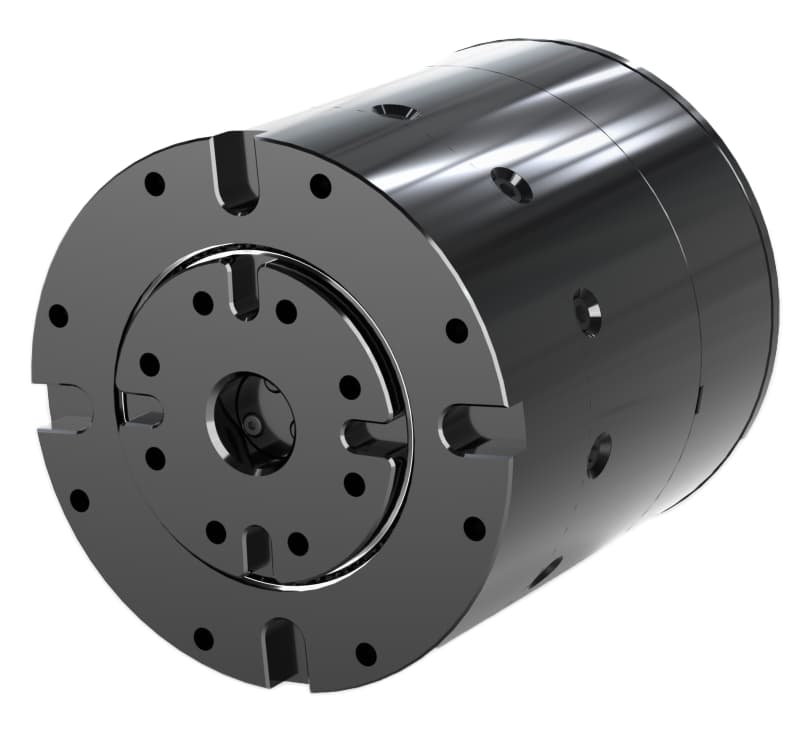
Integrated planetary and harmonic joint actuators

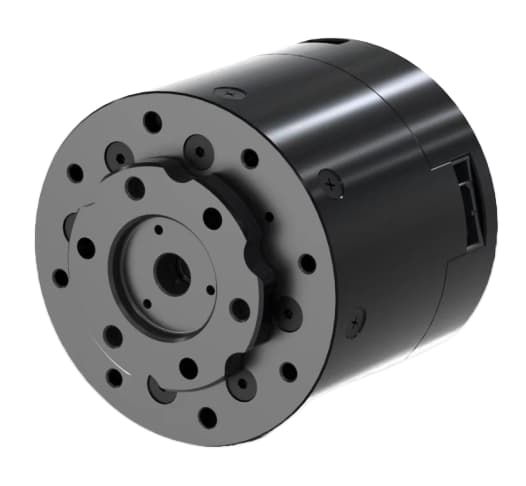
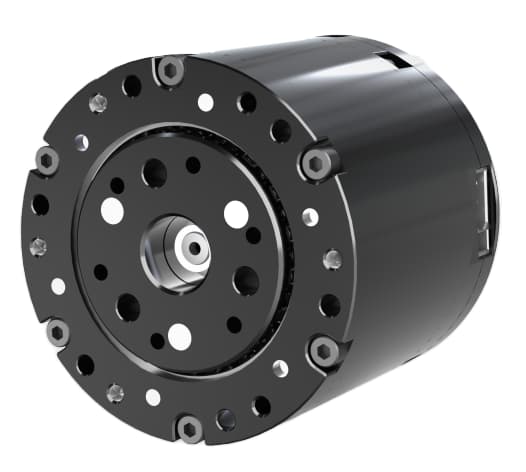
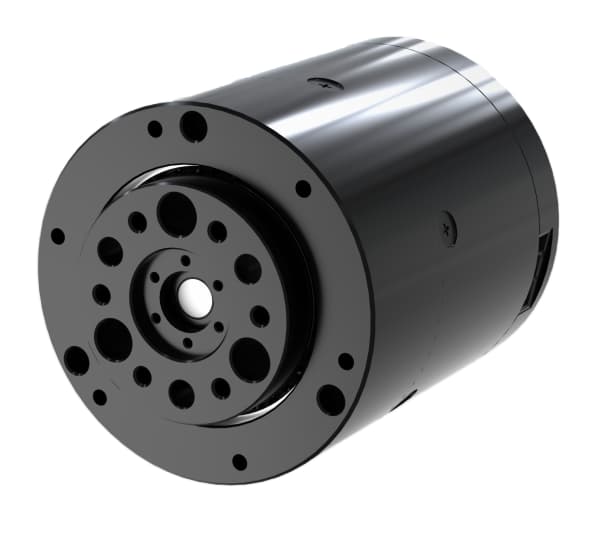
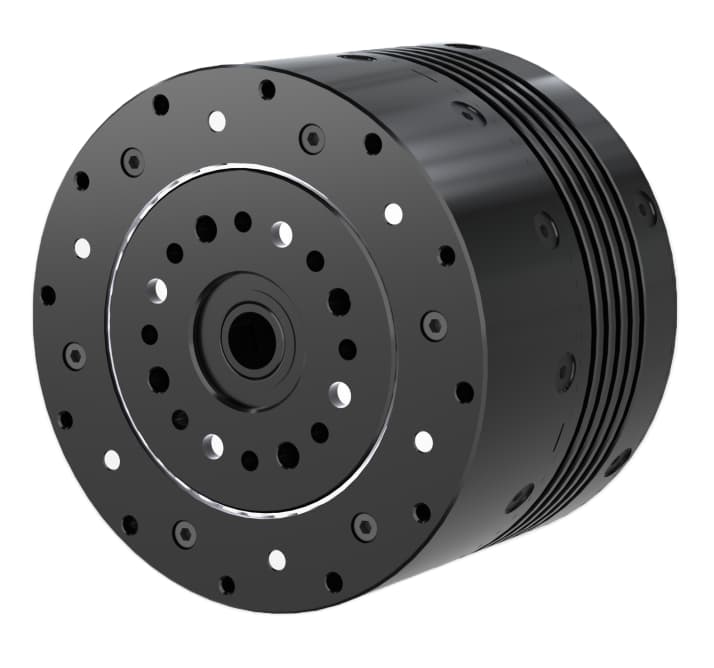
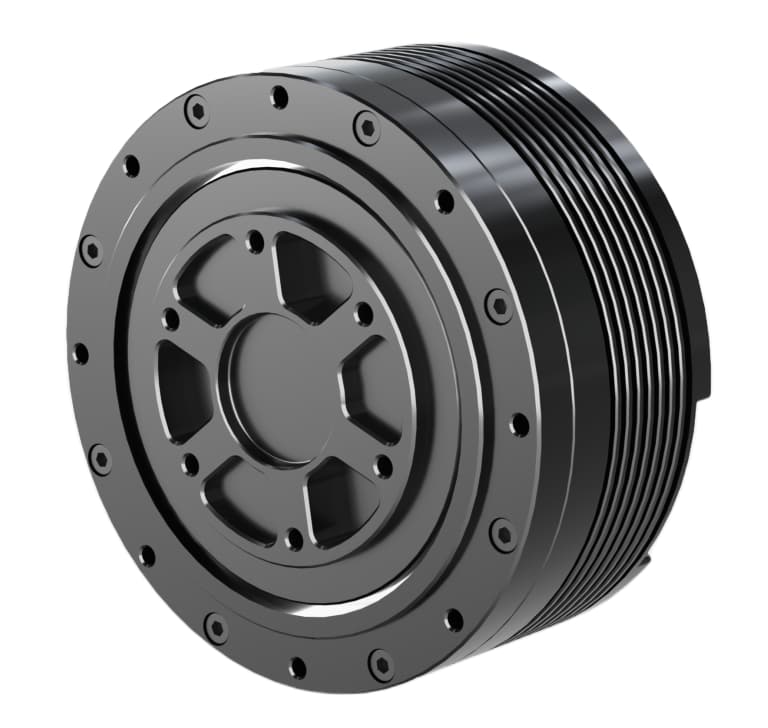
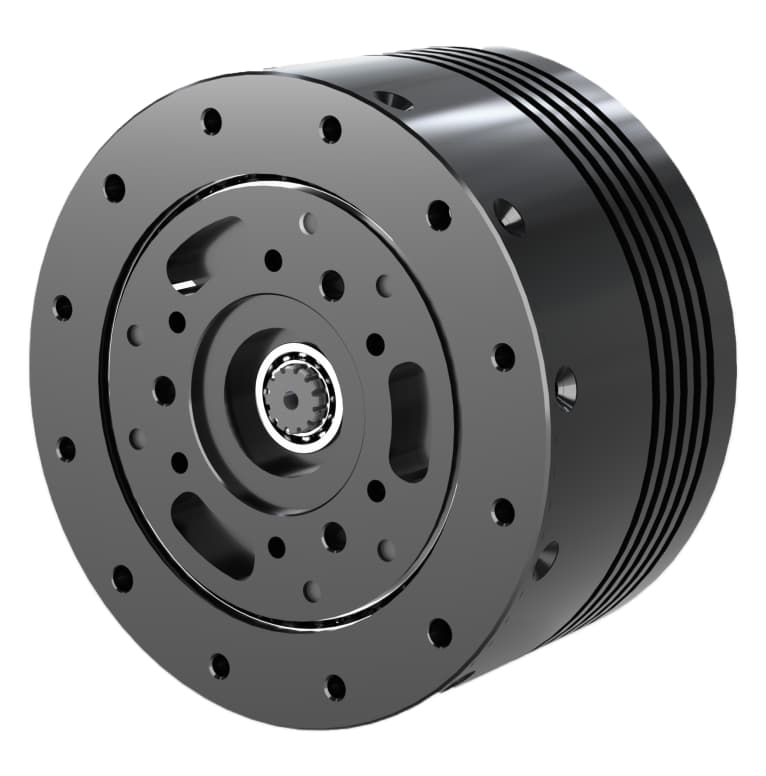
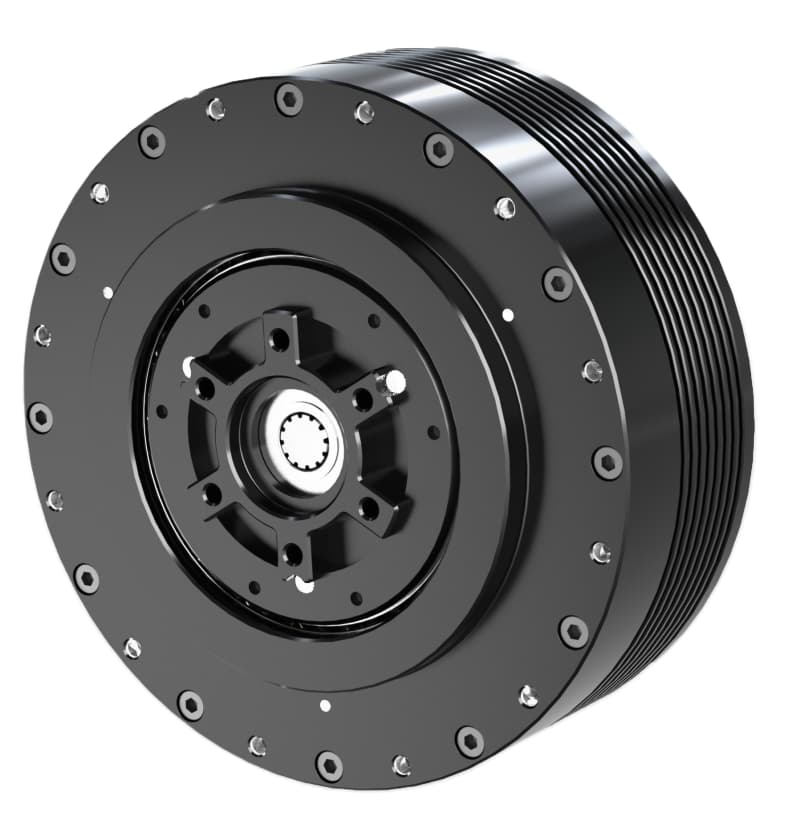
Compare source-verified torque, speed, ratio, mass, control, and interface fields before opening an engineering review. Every model record includes high-resolution visual references, 2D outline drawings, and source performance maps.

14

Total Models (13 Planetary, 1 Harmonic)

18–108 Nm

Peak Output Torque Span

10:1–100:1

Reduction Ratio Range

263–2220 g

Integrated Actuator Mass

Planetary reducer

Planetary joint-actuator models

Engineered for dynamic robotic limbs, quadrupeds, and high-cadence automation. Review rated output, peak torque (>3 s), reduction ratio, speed, weight, and verified interface drawings.

This catalogue entry is unusual in the set because both Model 1 and Model 2 columns are populated. The source lists different ratios, torque, speed, and mass for those columns, but does not explain their relationship. Compare each column as a separate source configuration and confirm the intended build before choosing one.

Rated torque
6 Nm
Peak torque (>3 s)
18 Nm
Rated speed
100 RPM
Peak speed
140 RPM
Reduction ratio
25:1
Actuator weight
263 g

The source publishes one configuration with a 40:1 reduction ratio, 10 Nm rated torque, 30 Nm under the source’s “Peak torque (>3 s)” table label, and 88 rpm peak speed. Its ratio and output-speed figures should be screened together against the required joint motion profile.

Rated torque
10 Nm
Peak torque (>3 s)
30 Nm
Rated speed
31 RPM
Peak speed
88 RPM
Reduction ratio
40:1
Actuator weight
356 g

The Model 1 table lists 20 Nm rated torque and 70 Nm under the source’s “Peak torque (>3 s)” label at a 36:1 ratio. The catalogue also mentions a custom steel output plate for high-impact conditions, including ankle-joint examples; request the exact option drawing and validation basis before treating it as a project fit.

Rated torque
20 Nm
Peak torque (>3 s)
70 Nm
Rated speed
80 RPM
Peak speed
117 RPM
Reduction ratio
36:1
Actuator weight
530 g

The feature notes specify a 9 mm through-bore and say that a brake is not supported. The Model 1 table lists a 16:1 ratio, 10 Nm rated torque, and 25 Nm under the source’s “Peak torque (>3 s)” label. Confirm that the drawing, cable-routing need, and no-brake boundary match the assembly.

Rated torque
10 Nm
Peak torque (>3 s)
25 Nm
Rated speed
130 RPM
Peak speed
174 RPM
Reduction ratio
16:1
Actuator weight
660 g

The source pairs a 39:1 reduction ratio with 25 Nm rated torque, 76 Nm under the source’s “Peak torque (>3 s)” label, and 100 rpm peak speed. It also lists 1.2 Nm backdrive torque. Treat that value as a catalogue parameter to review under the intended mechanics; it does not by itself establish a QDD classification or a backdrivability guarantee.

Rated torque
25 Nm
Peak torque (>3 s)
76 Nm
Rated speed
80 RPM
Peak speed
100 RPM
Reduction ratio
39:1
Actuator weight
640 g

The Model 1 table lists 16 Nm rated torque, 50 Nm under the source’s “Peak torque (>3 s)” label, a 36:1 ratio, and 67 rpm peak speed. The source also mentions a 100 KV version without defining its full configuration; ask for the exact winding/version data before comparing it with the listed table.

Rated torque
16 Nm
Peak torque (>3 s)
50 Nm
Rated speed
50 RPM
Peak speed
67 RPM
Reduction ratio
36:1
Actuator weight
610 g

Both Model 1 and Model 2 are populated, and the source gives both a 36:1 ratio. The visible table still lists separate electrical and output values, so compare the complete columns rather than assuming the labels mean interchangeable options. Model 1 is listed at 82 Nm peak torque and 64 rpm peak speed.

Rated torque
27 Nm
Peak torque (>3 s)
82 Nm
Rated speed
30 RPM
Peak speed
64 RPM
Reduction ratio
36:1
Actuator weight
630 g

The catalogue notes a 9 mm through-bore and says the standard configuration does not support a brake. Model 1 is listed at 30 Nm rated torque, 90 Nm under the source’s “Peak torque (>3 s)” label, a 25:1 ratio, and 88 rpm peak speed. Other KV versions are mentioned but need exact configuration confirmation.

Rated torque
30 Nm
Peak torque (>3 s)
90 Nm
Rated speed
50 RPM
Peak speed
88 RPM
Reduction ratio
25:1
Actuator weight
1000 g

The source lists an 18.33:1 reduction ratio with 30 Nm rated torque, 90 Nm under the source’s “Peak torque (>3 s)” label, and 190 rpm peak speed. Check torque, speed, and duty together; the single peak value is not a continuous operating point.

Rated torque
30 Nm
Peak torque (>3 s)
90 Nm
Rated speed
150 RPM
Peak speed
190 RPM
Reduction ratio
18.33:1
Actuator weight
900 g

The Model 1 values are 33 Nm rated torque, 110 Nm peak torque for more than 3 seconds, an 18:1 ratio, and 160 rpm peak speed. The source states standard CAN and EtherCAT communication and separately notes a 100 KV version; confirm the interface and exact motor version for the intended controller.

Rated torque
33 Nm
Peak torque (>3 s)
110 Nm
Rated speed
100 RPM
Peak speed
160 RPM
Reduction ratio
18:1
Actuator weight
1100 g

Both source configuration columns use a 10:1 ratio, but the remaining electrical and output values differ. Model 1 is listed at 40 Nm rated and 170 Nm peak torque with 192 rpm peak speed. Review the full Model 1/Model 2 tables and ask which configuration produced the performance map.

Rated torque
40 Nm
Peak torque (>3 s)
170 Nm
Rated speed
120 RPM
Peak speed
192 RPM
Reduction ratio
10:1
Actuator weight
1350 g

Model 1 lists 60 Nm rated torque, 300 Nm under the source’s “Peak torque (>3 s)” label, an 18:1 ratio, and 106 rpm peak speed. The source says a brake can be customized and the standard configuration has no through-bore. Treat the brake as a project option requiring confirmation, not as included hardware.

Rated torque
60 Nm
Peak torque (>3 s)
300 Nm
Rated speed
60 RPM
Peak speed
106 RPM
Reduction ratio
18:1
Actuator weight
1675 g

The source lists 80 Nm rated torque and 400 Nm under the source’s “Peak torque (>3 s)” label at an 18:1 ratio, with 80 rpm peak speed and 2,220 g mass for Model 1. It states no standard through-bore or brake support. Validate the required torque duration, mounting envelope, and mass in the actual mechanism.

Rated torque
80 Nm
Peak torque (>3 s)
400 Nm
Rated speed
50 RPM
Peak speed
80 RPM
Reduction ratio
18:1
Actuator weight
2220 g
Harmonic reducer

Harmonic joint-actuator model

Designed for precision cobot joints, pan-tilt heads, and high-reduction transmission envelopes requiring zero-backlash characteristics and high torque density.

This is the harmonic-drive record in the set. Model 1 lists a 100:1 ratio, 108 Nm rated torque, 304 Nm under the source’s “Peak torque (>3 s)” label, 62 rpm peak speed, and 1,600 g mass. The catalogue mentions through-bore, brake, and torque-sensor customization; request the exact option stack and resulting drawing before selection.

Rated torque
108 Nm
Peak torque (>3 s)
304 Nm
Rated speed
46 RPM
Peak speed
62 RPM
Reduction ratio
100:1
Actuator weight
1600 g

01 · Torque and speed

Screen the complete motion profile

Compare rated and peak labels with acceleration, peak duration, repetition, reversal, and thermal conditions.

02 · Interfaces

Check mechanical and electrical fit

Match the drawing, mounting, load path, cable route, voltage, connectors, protocol, encoder, and brake requirements.

03 · Evidence

Confirm the actual configuration

Request the current drawing, applicable performance map, test conditions, and validation evidence for the configuration being reviewed.

Confirm for your project

Need help narrowing the joint-actuator comparison?

Send the target torque and speed profile, duty cycle, mounting/interface drawing, supply and control requirements, project stage, quantity range, and validation needs. An initial review identifies missing inputs without assuming a model is suitable.

An initial review identifies missing inputs and next steps. It does not by itself confirm feasibility, performance, price, or delivery timing.